
AR4 MK3 J4 calibration flipped?
While calibrating the AR4 MK3 I found out that it got stuck on the 4th joint, to my mind the joint rotates the wrong way during calibration. (See video) Because of this if you don't pay attention the cables get stuck.
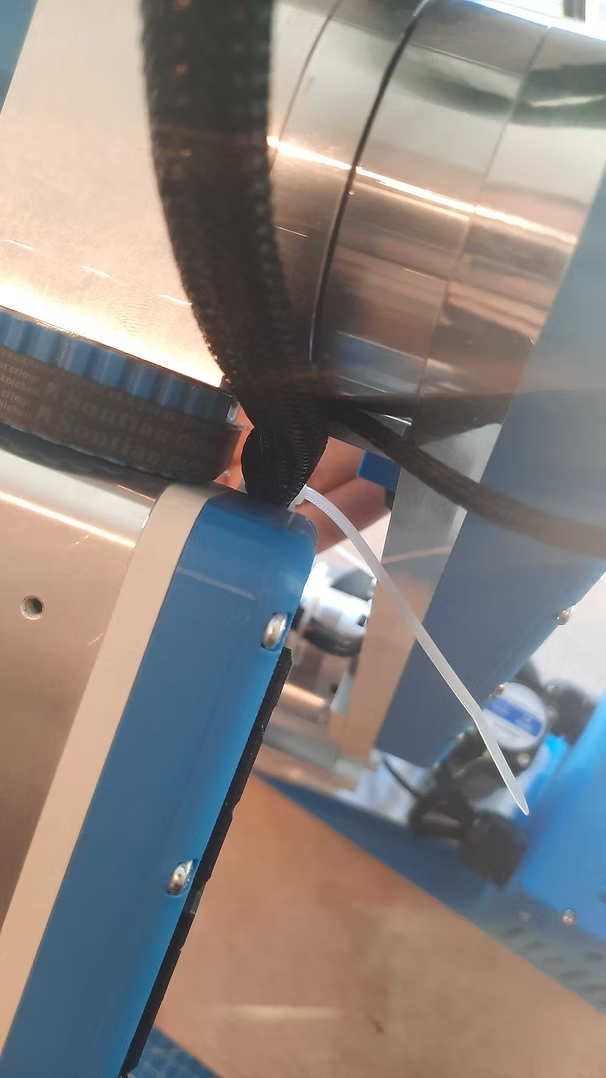
J4 does turn the right way during manual use in the program so the polarity of the stepper is correct.
Is this normal behavior and should I do my cable routing better or is there a value to be changed in the code?
Thanks in advance,
Daan Sijnja
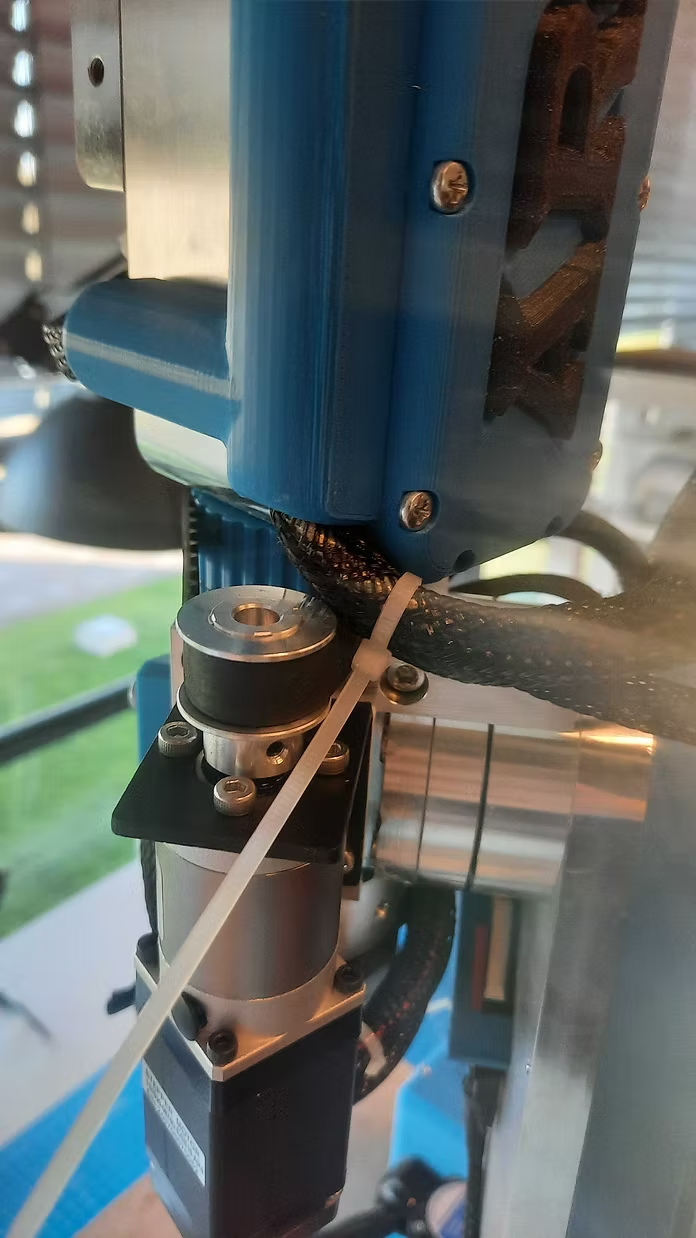
I found out what is wrong, i build the J4 stepper motor with a 90 degree anitclockwise rotation i found this after analyzing the startup video you made I saw that your j4 arm doesn't need to rotate as far as the one I put together
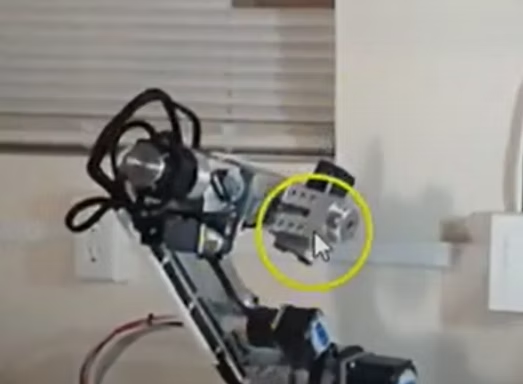
This is the point where the arm stops in the video,
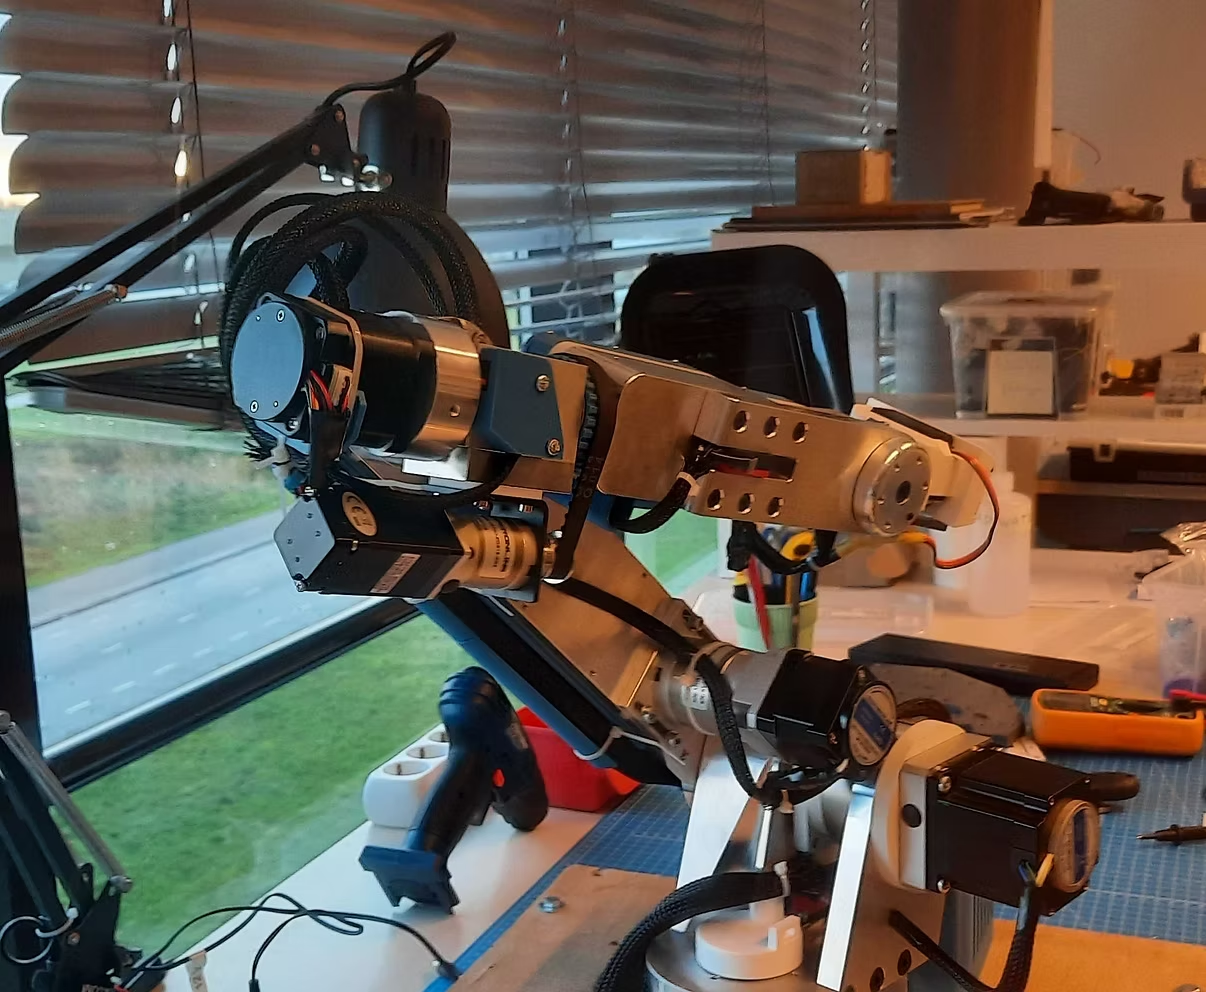
This is the the Arm that i built in roughly the same position as in the video.
and this is the screw position. So im going to reassemble it correctly. The only thing is that I couldn't find it in the build manual as an attetion point. Thanks in advance, Daan Sijnja
3 replies
Chris Annin
Are the cables being pinched or causing the joint to jam or lock up? It does look like the J6 cables should be a bit further to the right and tied to the J5 limit switch cable.