


I am currently working with the AR4 MK3 and have integrated a DC motor-powered linear actuator at the end effector. My goal is to manually control the robot using an Xbox controller to record positions and trajectories for later playback.
Currently, I’m using a physical toggle switch on the arm to operate the actuator through a program i wrote on the HMI, but I’m looking for a more seamless solution. Is there a way to define the DC motor as a 7th axis so it can be controlled via an xbox controller?

Hi everyone — not sure if this type of post is allowed, so please feel free to remove if not.
I’ll be moving back home to Australia soon, and unfortunately, the shipping costs are too high for me to bring my partially assembled AR4 MK2 kit along.😭
The kit includes everything you need: the aluminium frame kit, stepper motor kit, 3D printed components, and all miscellaneous items — all purchased separately from Amazon.
Selling the entire set for $800 USD.
Pickup preferred in Houston, TX (Medical Center area)
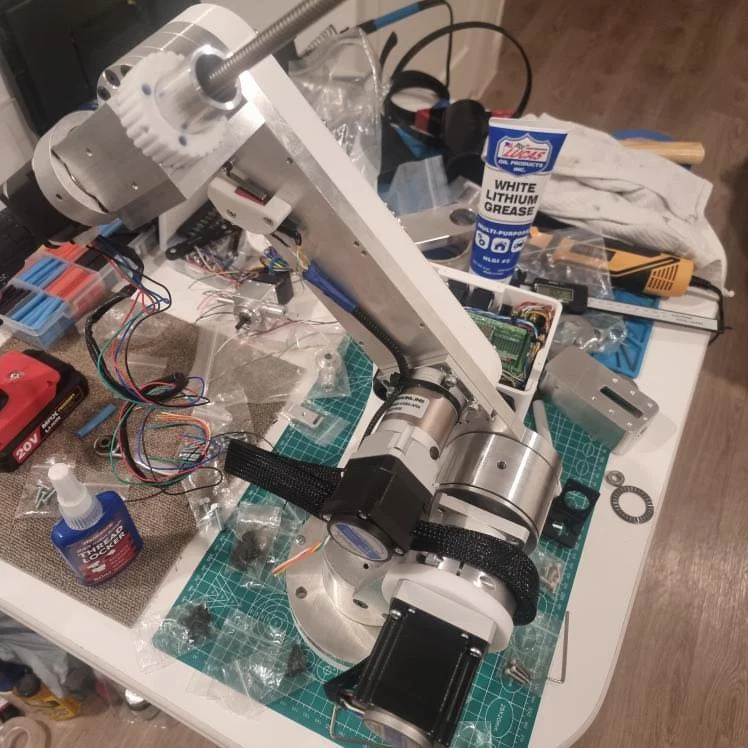
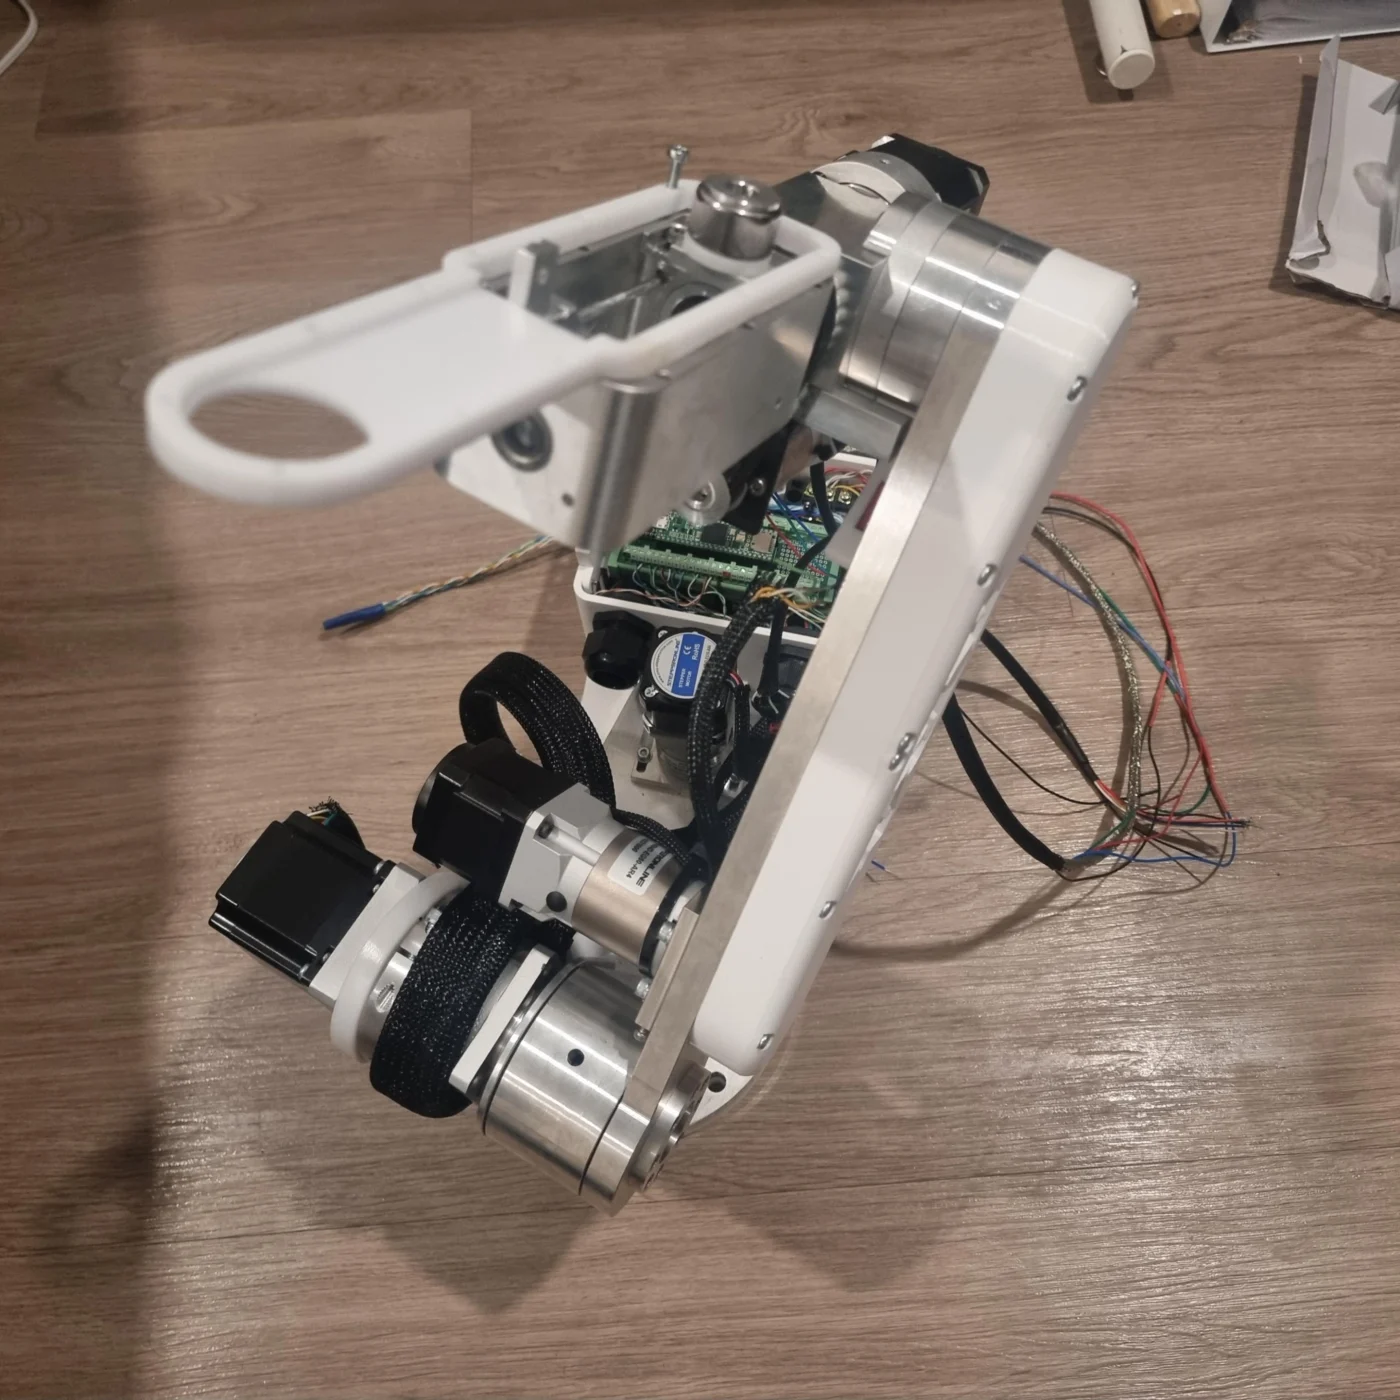
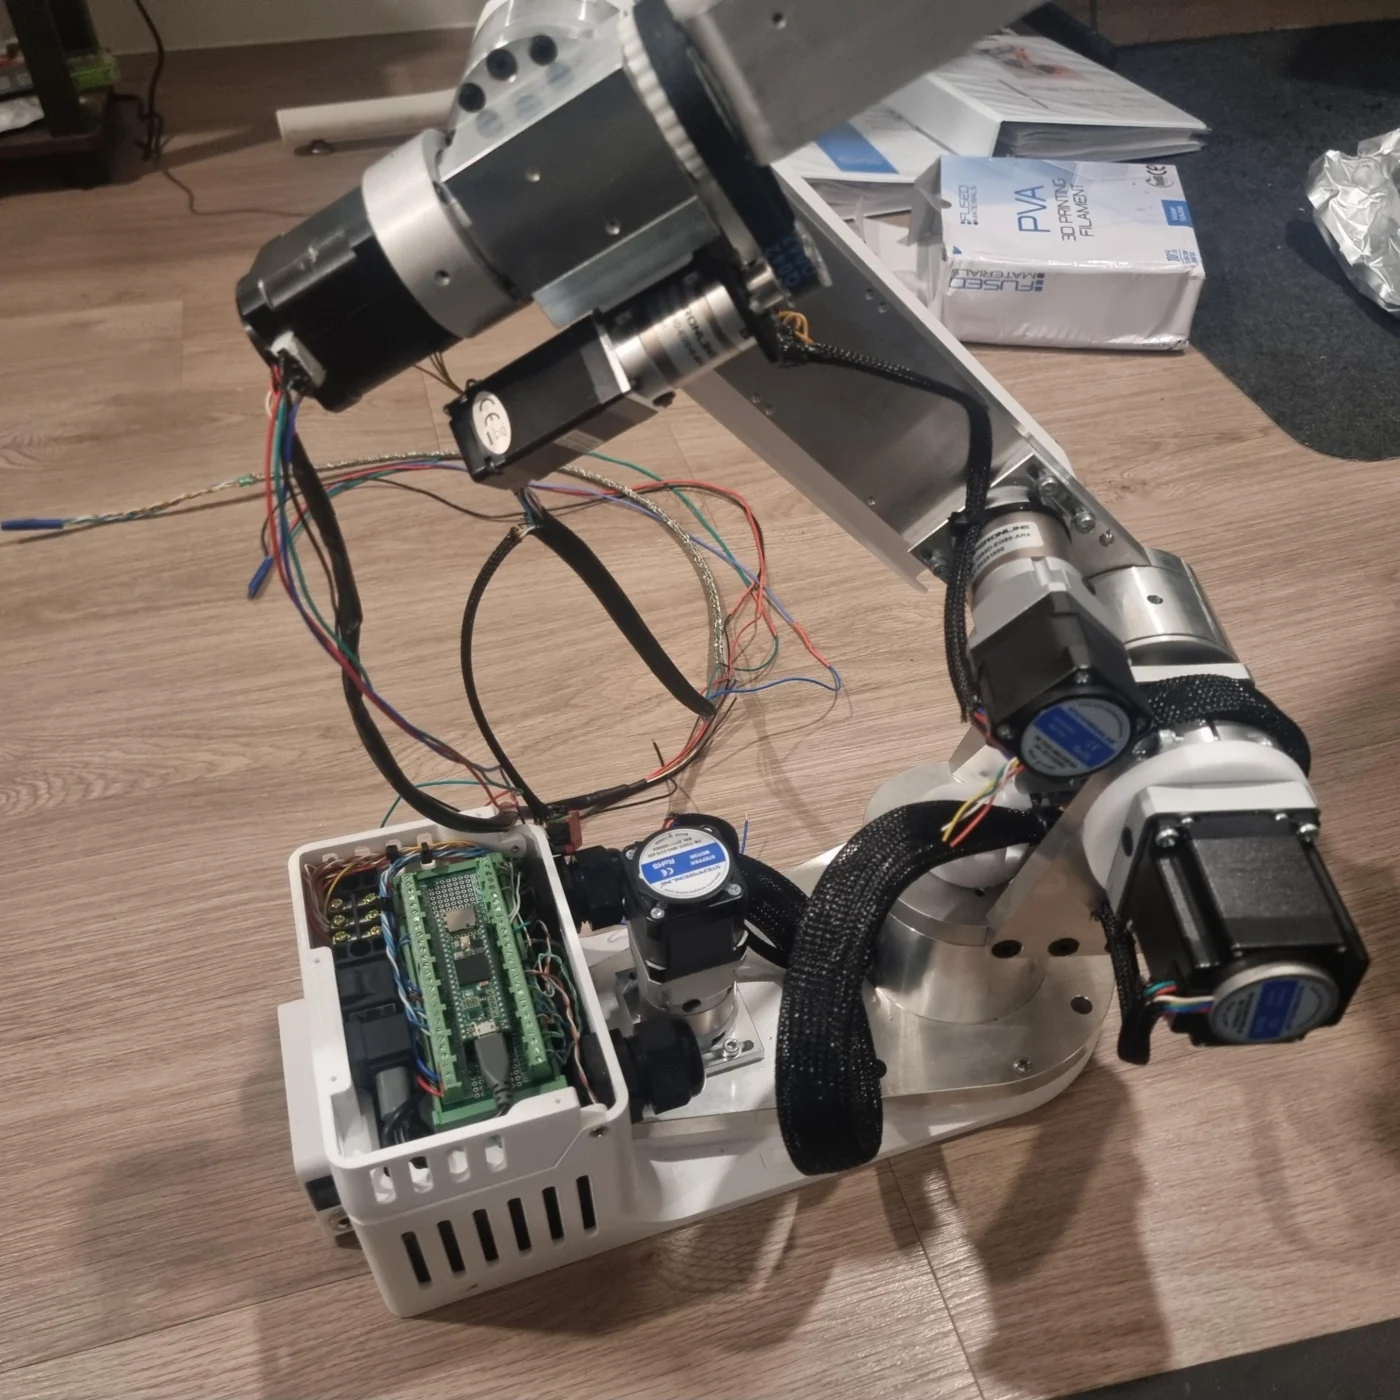

Please help me,Excuse me, family.I have an AR2 open loop robotic arm, and nowI want to replace the controlwith a teensy4. 1 control board.Can the previous control code programstill be used? How can I modify it so that I can control the mechanical arm' s operation? Is there anything I should pay attention to? Thank you

Hi everyone,
I am writing to confirm if the Annin Robotics AR4 (MK4) can support a ball-throwing application using its default stepper motor set.
Specifically, I want to throw a 100-250 gram light weight ball in defined bucket at particular distance (TBD). For reference, the stepper motor and specifications are as follows:
- J1 motor: 17HS15-1684D-EG10-AR4
- J2 motor: 23HS22-2804D-YGS50-AR4
- J3 motor: 17HS15-1684D-EG50-AR4
- J4 motor: 11HS20-0674D-EGS16-AR4
- J5 motor: 17E19S1684MB4-200RS-AR4
- J6 motor: 14HS11-1004D-EGS20-AR4
- J4 bracket: ST-M3
Based on above specs, Do you believe the default stepper motors can handle the required torque and speed for this application? Do you see any challenges with stepper motor? If someone has achieved similar application, please share this details with us.

Hello everyone, the equipment space is very tight. The servo motor is directly plugged into the input end of the right-angle planetary gearbox (https://www.oyostepper.com/category-192-b0-Right-Angle-Planetary-Gearbox.html), with no space for a coupling.
I'm worried that the motor shaft and the gearbox input hole are not concentric, which will damage the bearings over time. However, there's no space to fit a dial indicator, and visual alignment is unreliable.
Are there any simple methods to roughly confirm the alignment? For example, using a feeler gauge or a coloring method? Or, with this type of direct-insertion structure, as long as the flange mounting surface is machined to a sufficient precision, there's generally no need to worry?
I hope an expert can help me.
Help me!Does anyone know the DH parameters for AR 3? I upgraded my AR 3 to AR 4, I don't know if his DH parameters are universal? If anyone knows the relevant DH parameters, please send them to me, I need relevant DH information.thank you.

Hi, anyone know how I can teach a sequence of tool moves say I want to rotate around the tool reference how do I do that. I can move it this way manually (Trx, Try, Trz) but what type of moves do I use to do it in a program?
Thanks

When I jog j5 it is pulling the 2 rods out of the housing
Trying to figure out what exactly went wrong there, it seems the set screws are not holding them in all the way and they come out easily, even when tightened to max.
One thing that could potentially be a problem, I can't tell from pictures.. is when I push the rods all the way in the housing, they are still protruding about 1-1.5mm instead of being perfectly flush.
So maybe that is why the set screws are not holding them in.
Can anyone confirm?
When the J and L codes are output from an external program, the robot joints it interprets are different from the program's positioning. Is there a way to resolve this? In the CAM program, the 4th and 6th axes are set to 0 and processed, but when I load the program from AR4 and operate it, the 4th and 6th axes behave unpredictably. When I program it using the R mechanical joints, it works normally. However, when I operate it using the R joint coordinates, the acceleration and deceleration are completely different. Is there a way to resolve this? Even when I measure the position using J and L movements in AR4 and operate it, the joints rotate 180 degrees, causing the robot to catch a rat.
EX:
Sp 50 Ac 15 Dc 15 Rm 80 $ N
Move R [*] J1 0 J2 3.312 J3 16.713 J4 0 J5 -20.026 J6 0 J7 0 J8 0 J9 0 Sp 50 Ac 20 Dc 20 Rm 50 $ N
First Toolpath Point
Sp 50 Ac 15 Dc 15 Rm 80 $ N
Move R [] J1 -28.17 J2 17.807 J3 -0.054 J4 0 J5 -17.753 J6 0 J7 0 J8 0 J9 0 Sp 50 Ac 20 Dc 20 Rm 50 $ N
Move R [] J1 -28.17 J2 18.224 J3 0.556 J4 0 J5 -18.78 J6 0 J7 0 J8 0 J9 0 Sp 50 Ac 20 Dc 20 Rm 50 $ N
Plunge Move Starts
Sp 20 Ac 15 Dc 15 Rm 80 $ N
Move R [*] J1 -28.17 J2 18.756 J3 1.255 J4 0 J5 -20.01 J6 0 J7 0 J8 0 J9 0 Sp 20 Ac 20 Dc 20 Rm 50 $ N
Cutting Move Starts
EX1:
Sp 15 Ac 25 Dc 25 Rm 80 $ N
Move J [*] X 350.002 Y 0.000 Z 109.999 Rz 0.000 Ry 0.000 Rx 0.000 J7 0 J8 0 J9 0 Sp 15 Ac 25 Dc 25 Rm 80 $ N
First Toolpath Point
Sp 15 Ac 25 Dc 25 Rm 80 $ N
Move L [] X 358.553 Y -192.014 Z 110.000 Rz -28.169 Ry 0.000 Rx 0.000 J7 0 J8 0 J9 0 Sp 15 Ac 25 Dc 25 Rm 80 $ N
Move L [] X 358.553 Y -192.014 Z 105.000 Rz -28.169 Ry 0.000 Rx 0.000 J7 0 J8 0 J9 0 Sp 15 Ac 25 Dc 25 Rm 80 $ N
Plunge Move Starts
Sp 20 Ac 25 Dc 25 Rm 80 $ N
Move L [*] X 358.553 Y -192.014 Z 99.000 Rz -28.169 Ry 0.000 Rx 0.000 J7 0 J8 0 J9 0 Sp 20 Ac 25 Dc 25 Rm 80 $ N
Cutting Move Starts


This firmware works quite stably 6.6