


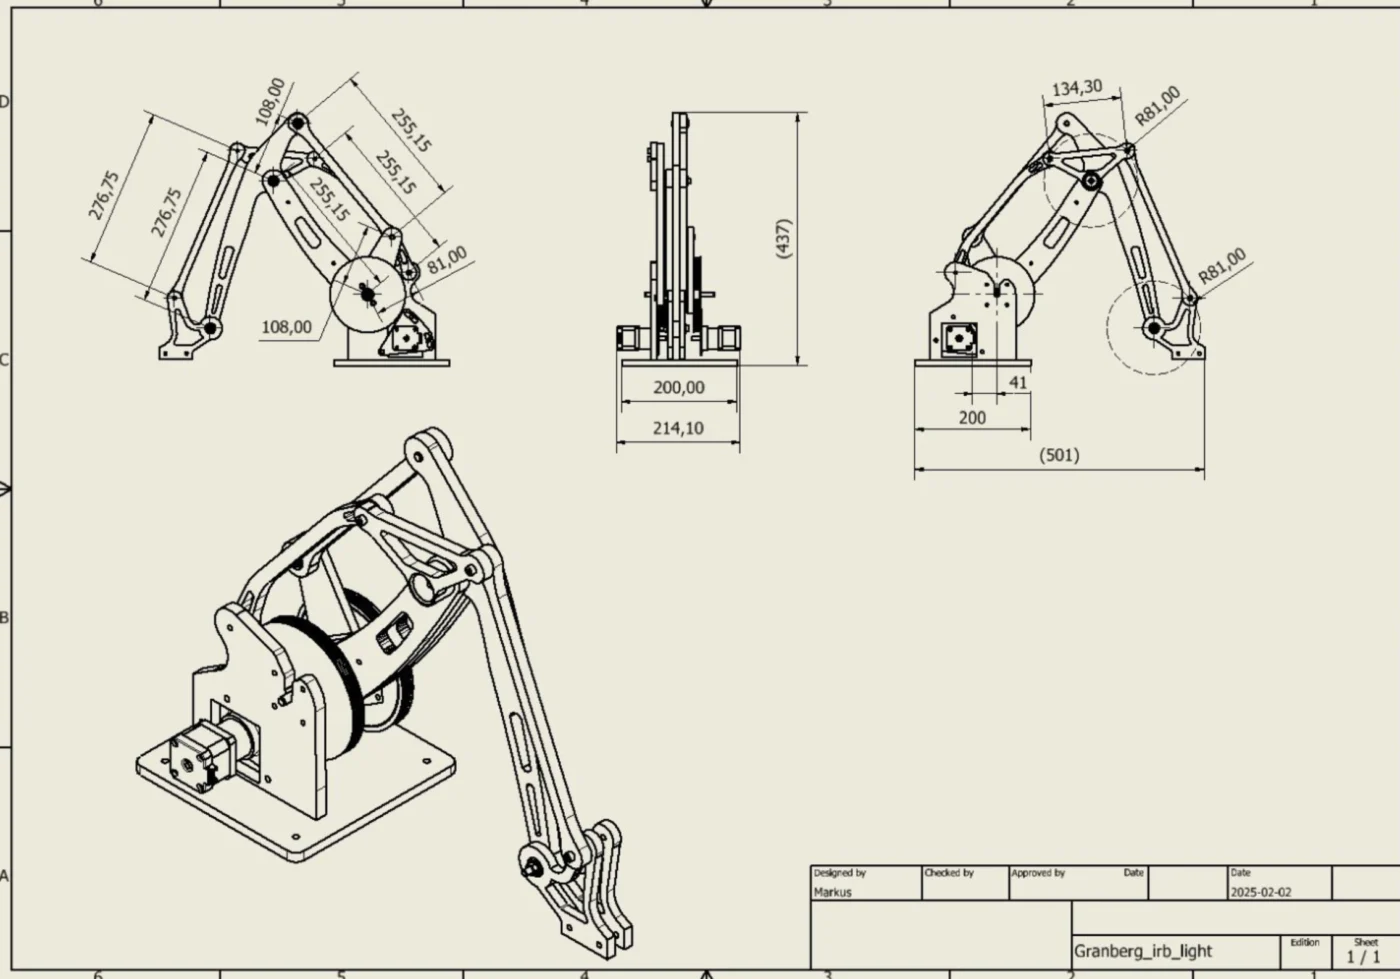
Hi, I built a 3DOF arm (base, shoulder, elbow, parallelogram). Can AR4 software’s 3rd party robot option support this? D
Hi everyone,
I’ve built my own robot arm that’s a bit simpler than the AR4 — it has a rotating base, a shoulder joint, and an elbow joint (3 DOF in total). The arm also uses a parallelogram linkage to keep the end effector oriented.
I read that the AR4 software has support for “3rd party robot design.” Would it be possible to describe a robot like mine in that system and run it with the AR4 controller + software?
Is it enough to specify link lengths, joint order, and limits, or does the inverse kinematics code also need to be modified?
Has anyone here successfully run a simpler 2–3 DOF robot through the AR4 software?
My main goal is to take advantage of the teach mode and interface, but with my own hardware setup. Any guidance or examples would be greatly appreciated!
Thanks in advance

Hello, the robot kinematics are specific to a 6DOF robot but you can still use the software in a limited fashion using joint mode. You could still follow the wiring diagram in the AR4 manual omitting the unused joints, when you program you would have to use Move R in the program which are joint rotation commands and simply jog and teach positions according to each joints angle rather than cartesian positions.