
Payload
1.9 kg rated vs 750 g including the tool.
Compare
Thor and the AR4 are two of the best known open source six axis arms you build yourself. Thor is a fully 3D printed project you source part by part for very little money. The AR4 is a machined aluminum arm sold as a kit, with closed loop joints and more than twice the payload.
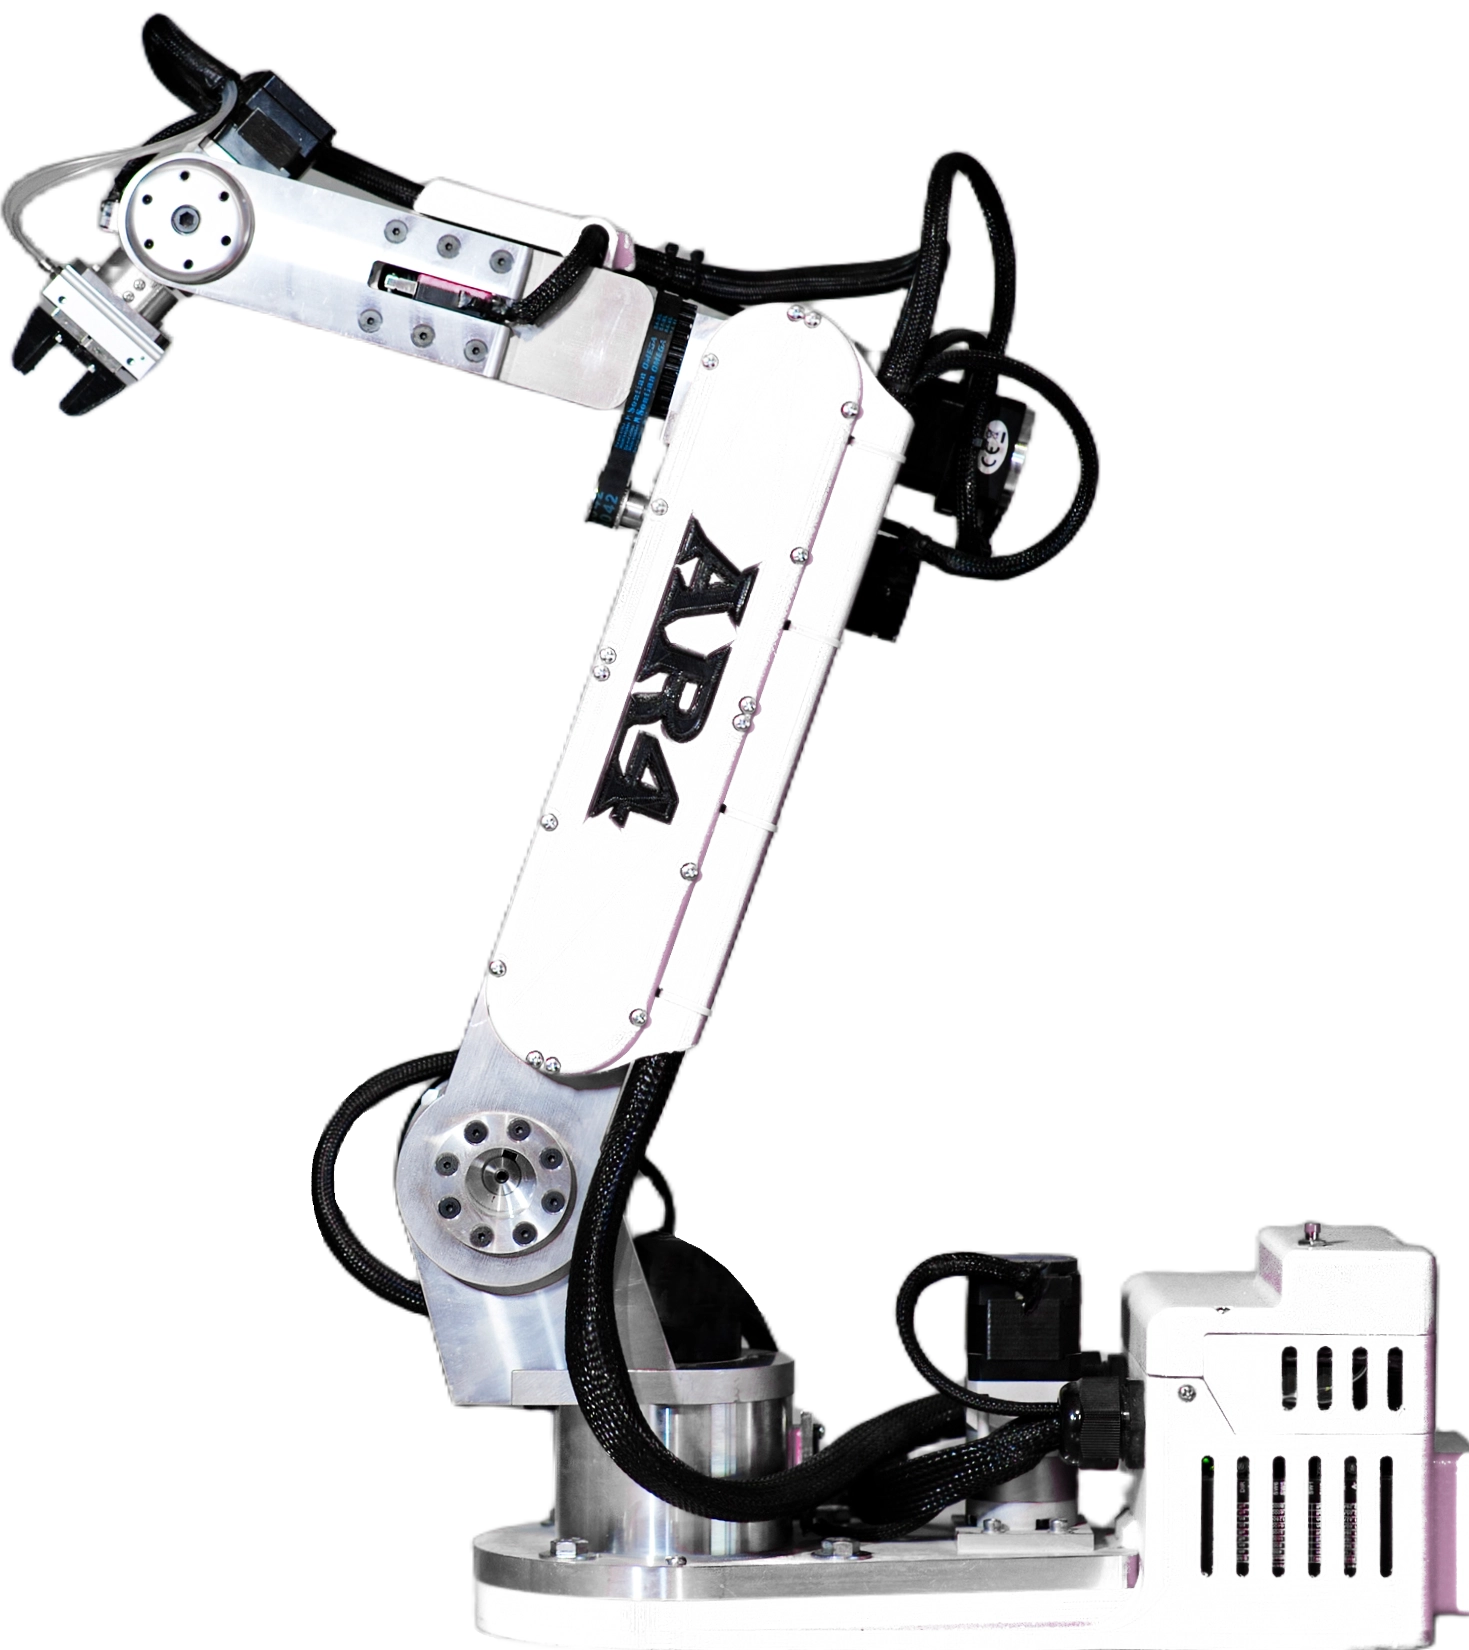
Thor open source robot arm
by AngelLM (Thor project). See the maker's page in Sources for photos.
$0
AR4 combo kit with motors
€0
Thor hardware cost, under (per the project)
0 g
Thor max payload incl. tool
0.0 kg
AR4 payload
Overview
Anyone searching for an open source robot arm to build will find Thor and the AR4 within minutes of each other. Both have six axes in the same layout used by industrial robots, both are fully open, and both are popular in schools and maker communities.
The real choice is between printing everything yourself and building from a machined kit. Thor is a remarkable free design you source and print part by part. The AR4 is a commercial kit with aluminum structure, closed loop joints, and support. The comparison below uses the Thor project's own documentation and our spec sheet.
Specs
The AR4 wins 5 rows and the Thor wins 1. AR4 values are from the AR4-MK5 specification sheet. Thor values are from AngelLM (Thor project)'s own pages, listed under Sources. "Not published" means the maker does not list it.
| Spec | Annin AR4-MK5 | Thor open source robot arm |
|---|---|---|
| AxesEven | 6 | 6 (yaw roll roll yaw roll yaw) |
| Reach | 629 mm (24.75 in) | Not published. 625 mm tall fully stretched. |
| PayloadAR4More than twice the payload | 1.9 kg (4.15 lb) | 750 g max, including the tool |
| Repeatability | 0.25 mm | Not published |
| StructureAR4Machined aluminum structure | 26 machined aluminum structural parts, 3D printed PETG covers | 3D printed (3 to 4 kg of PLA or PETG), printed gears |
| Position feedbackAR4 | Closed loop encoders on every joint | Open loop steppers on A4988 drivers, with endstops (per the BOM) |
| Build effortAR4 | Kit with machined parts, full build manual and videos | About 200 h of printing plus about 10 h of assembly, per the project FAQ |
| SoftwareEven | Python HMI with digital twin, ROS 2, Modbus, G-code | G-code on GRBL or RRF firmware, ROS 2 via Docker |
| Open sourceEven | Mechanical design, electronics, firmware, and software are all open | All files open under CC BY-SA 4.0 |
| PriceThorFar cheaper if you have a printer | Combo kit $1,229 plus $699 motor package ($1,928 total) | Hardware cost below €350, sourced part by part |
| BuyingAR4 | Sold as kits, with every part sold separately | Not sold. You source and print every part. |
AR4 advantages
1.9 kg rated vs 750 g including the tool.
Machined aluminum vs printed plastic and printed gears.
Encoders on every joint vs open loop steppers with endstops.
No 200 hours of printing. Every part is also sold on its own.
Thor advantages
Hardware below €350 if you print it yourself, vs $1,928 for the AR4 kit.
A 200 by 200 mm printer is enough, per the project.
CC BY-SA 4.0 keeps every derivative open.
Price
Thor is not sold. The project says the hardware costs below €350, which assumes you print around 3 to 4 kg of filament yourself and buy motors, drivers, and bearings from the bill of materials. That is far cheaper than the AR4, and we say so plainly.
A complete AR4-MK5 is $1,928, the $1,229 combo kit plus the $699 motor package. That buys machined aluminum parts, closed loop stepper motors, and electronics, all matched and shipped together. For a school or lab, one order replaces weeks of printing and sourcing.
See the AR4 MK5 combo kit or browse all AR4 robot kits, including the aluminum, hardware, and electrical kits sold separately.
Prices change. Check each store before you buy.
Software
Thor moves with G-code on GRBL or RepRapFirmware, the same language as 3D printers and CNC machines, and has a ROS 2 setup in Docker. Every file is open under CC BY-SA 4.0.
The AR4 is open source too, and ships with a free Python HMI that includes a digital twin, plus ROS 2, Modbus, and G-code. The difference is less about openness and more about the hardware the software drives.
Build and repair
Thor's structure, gears, and housings are printed, with around 3 to 4 kg of filament, and its bill of materials uses A4988 stepper drivers with endstops. That keeps cost low, but printed gears and open loop motors limit stiffness and how well the arm knows its own position.
The AR4 uses 26 machined aluminum structural parts and closed loop stepper motors with encoders, so missed steps are detected and corrected. Every part is sold separately, so repairs do not depend on your printer or on sourcing parts from many shops.
Read the full AR4-MK5 specifications for motors, gear ratios, and joint ranges.
Bottom line
FAQ
Yes. The Thor project lists a hardware cost below €350 when you print and source the parts yourself. A complete AR4-MK5 kit is $1,928.
Thor has lifted 750 g including the tool, per its FAQ. The AR4 is rated for 1.9 kg.
Yes. Thor publishes all files under CC BY-SA 4.0. The AR4 publishes its mechanical design, electronics, firmware, and software.
The Thor FAQ estimates around 200 hours of printing and about 10 hours of assembly. The AR4 kit ships with machined parts, so no structural printing is needed.
For a low cost print and build project, Thor. For a classroom arm that survives student use, carries real grippers, and comes as one kit, the AR4.
Machined aluminum, open source from the ground up, at a price a classroom can afford.
References
Thor figures retrieved from github.com/AngelLM/Thor and thor.angel-lm.com on October 26, 2026. Thor is an open source project by Ángel L.M. This page is not affiliated with or endorsed by the Thor project.