

Rewrite web service need help on python forward/inverse kinematic lib
Hi,
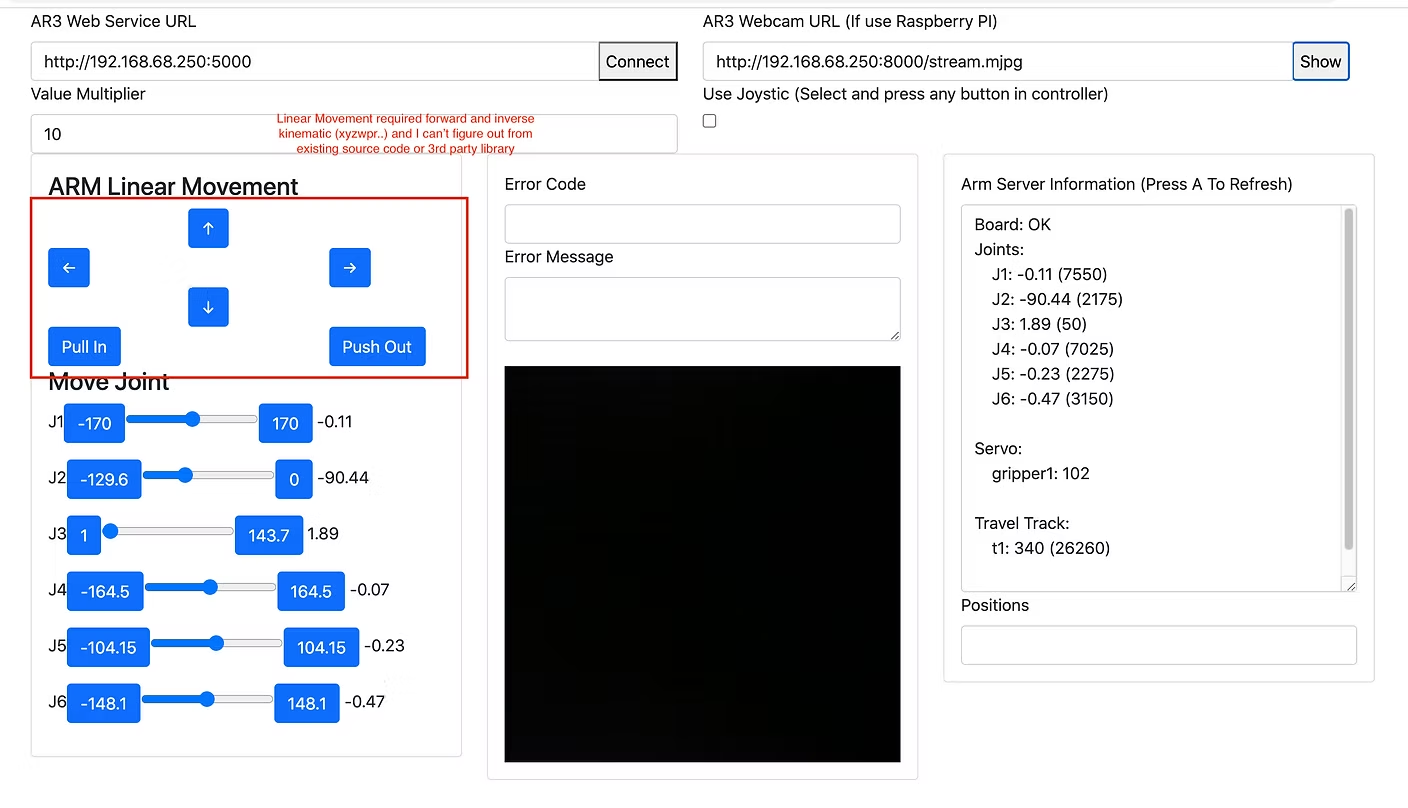
I'd developed web services of AR3 which allow us move J1-J6, Tracks and servo (repository at github). I wish to further enhance it to support linear movement however it require to kinematic calculation. ARCS have build in forward and inverse kinematic calculation, but it is so hard to port over and very confusing. I tried to find 3rd party library like robotics-toolbox-python (https://github.com/petercorke/robotics-toolbox-python) unfortunate I don't know how to implement it due to lack of explanation (or i'm noob in mechanical knowledge).
Below is the web UI I doing now
github.com
github.com/petercorke/robotics-toolbox-python

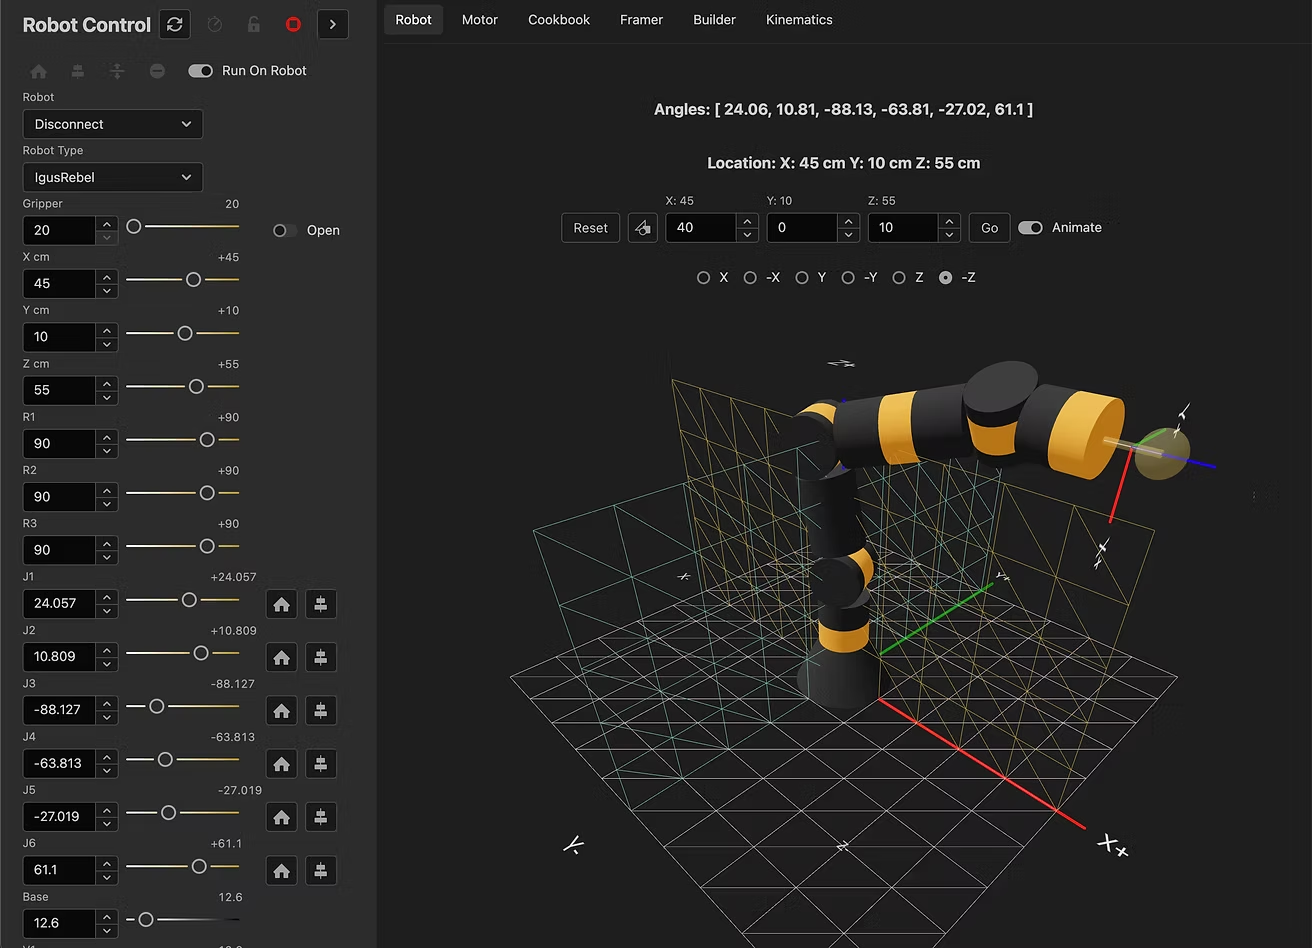
I have also built a web UI for this and it already has the kinematics and a simulator.
https://robot-viewer-qfmqx.ondigitalocean.app/
You can see more about all this on my channel
2 replies
Kstan Simit
i solved inverse kinematic calculation with minimal code by using python robotic toolbox
https://github.com/petercorke/robotics-toolbox-python/issues/199