
J4 is the only joint that moves (AR3) Teensy 4.1
I have a new build of the AR3 arm with the AR4 Teensy 4.1, Arduino Nano and external AR3 encoders
When running, I'm able to jog J4 stepper (DM320T Driver), however J1, J2, J3, J5, J6 (DM542T Driver) wont move, but do change in noise pitch when a jog command is sent.
-
I have checked A+ A-, B+ B- motor pairs at the driver plug for continuity - Check OK
-
Switched stepper wire pairs, at the driver, also switched +- with in the pairs - No Change
-
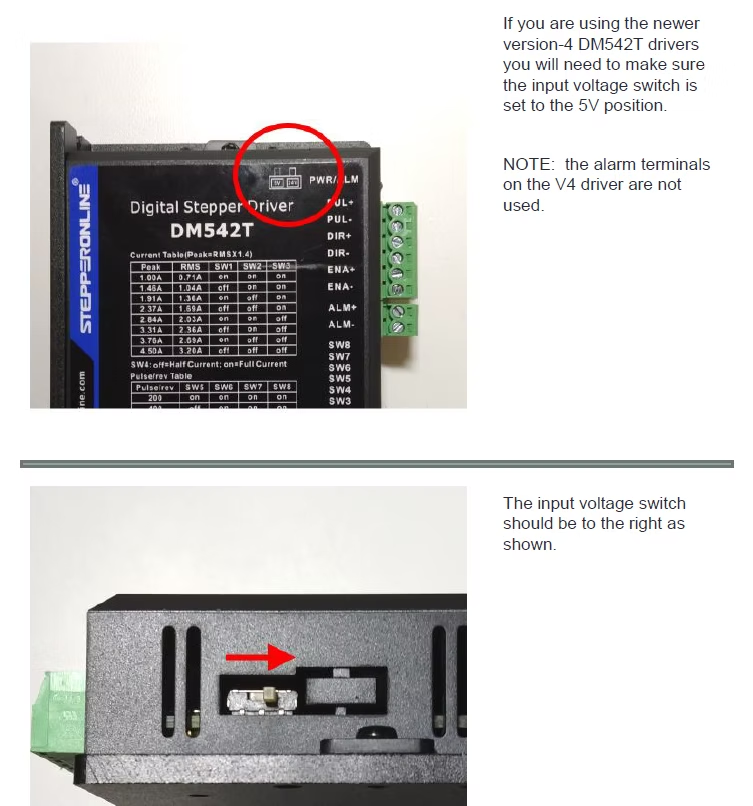
5v / 24v signal switch on the DM542T drivers toggled to both settings - No Change
-
Drivers are wired with 5v on the PUL+, DIR+. PUL- and DIR- wired to the teensy 4.1
-
DIR is seeing 5v, PUL has 1.7v and jumps to 1.8v with a jog command.
-
Driver DIR and PUL are wired with the same 5v + as the teensy 4.1
Is the 5v for the DIR and PUL too high for the teensy 4.1? (but why is J4 working)
-
24v power supply for the drivers.
-
12v/5v power supply for the teensy (5v), arduino nano (5v), relay board (12v), step down buck (3.3) for endstops and encoders. Common ground for all 3 voltages.
Should I tie the grounds together for the 24v and 12/5v power supply output voltages? (both wired off the same AC plug)
-
I have removed the connection between the teensy and the arduino nano, to rule it out - No Change
-
Endstops and encoders are powered with 3.3v
-
Cable length from controller to arm base is 2 meters
-
Driver cable is 18 awg stranded copper
Is the driver cable length too long? (but J4 is working fine)
-
Driver DIP switch settings checked, difference found between the AR3 and AR4 settings for J6, SW4, both tested - No Change
-
Teensy tested with AR4_teensy41_CUI_enc_sketch (BETA) (https://drive.google.com/file/d/1nU8GYRboUnC7agDtrH_aKICsT3lpSWBc/view?usp=sharing) and Teensy 4.1 sketch Ver 1.1 (https://drive.google.com/file/d/1xeRyWuSAsPC-4kgqZyDQw_OsfxPbBAyH/view?usp=sharing) - No Change
-
AR3 ARCS Ver 1.0 (exe), AR4 Version 1.1 (exe) and AR4 Version 1.3 (exe) - AR4 1.3 seems to be the most consistent and best so far.
-
Encoders are disabled in the AR4 software
-
EN is setup for the EM stop, when toggled the motors go limp, and firm when released, as expected,
-
Running windows 7
Any suggestions? as I have run out of things to try and this has got me stumped
Looking at the manuals for the DM542T https://www.omc-stepperonline.com/download/DM542T.pdf
Page 11, ENA signal ahead of DIR at least 5us
DM542T Ver 4.0 https://www.omc-stepperonline.com/digital-stepper-driver-1-0-4-2a-20-50vdc-for-nema-17-23-24-stepper-motor-dm542t
Page 10, ENA signal ahead of DIR at least 200ms
Drivers have been tested with both the ENA+- wired and unwired - No Change
Can that change be set or tested in the AR4 1.3 app?
drive.google.com
drive.google.com/file/d/1nU8GYRboUnC7agDtrH_aKICsT3lpSWBc/view?usp=sharing
Yes, see my third point, I could've worded it clearer after rereading it
when you said "12v/5v power supply for the teensy (5v)" are you using an external power supply for the teensy? I have never powered it from an external source but am using the USB power.
you also said "Endstops and encoders are powered with 3.3v" the AR4 wiring has the encoders powered with 5v and the limit switches with 3.3v. I have some notes on this in the document "upgrade to AR4" under the AR3 downloads. Im not certain the signal timing would have any bearing on this issue. The biggest indication in your notes is that the pitch changes when you try to jog axis 1,2,3,5,6 Im assuming all the dip switch settings are correct, as I said earlier the pitch has me concerned about the AABB wiring to the motors. If you could let me know on wiring questions above and perhaps email me some detailed pictures of your enclosure wiring this may help be spot any issues.
I found the source of the problem, me being a moron and not following the instructions properly, I have the teensy powered by an external power supply, and also had the power for the driver DIR and PUL powered from the same power supply (5v), I changed the power for the driver DIR and PUL to the 3.3v from the teensy 4.1 and it is working fine.
That mistake cost me a number of hours and beer (still puzzled why J4 worked though).
Have found the limit switches problem and encoders too, adjusting it now.
With regards to the teensy being powered externally, I snipped the 5v wire on a USB lead, thinking I could run the arm without a PC attached,
Since learning that, I am wanting plenty of current to power the encoders, teensy and limit switches, for say a raspberry pi (I've killed a few drawing too much current via USB)
6 replies
Chris Annin
Ok, that's typically the first thing I look at when only the DM320 drive is working. Did you have this robot operational previously with the AR3 software? When people report a noise or pitch I would look at the AABB driver/motor wiring. Out of curiosity have you tried swapping the cable currently being used on J4 to one of the other joints?