
AR4 MK3 in Finland
Hi!
Finished my build of the AR4 MK3 in Finland some time ago. Even recoded the time the build took me,
52.5 hours of slow, careful and deliberate work.
Ros2 is working thanks to ycheng @ https://github.com/ycheng517/ar4_ros_driver/
Below's a sample with Chris' software (object recognition) and one with ros 2 collision aware IK.
github.com
github.com/ycheng517/ar4_ros_driver/
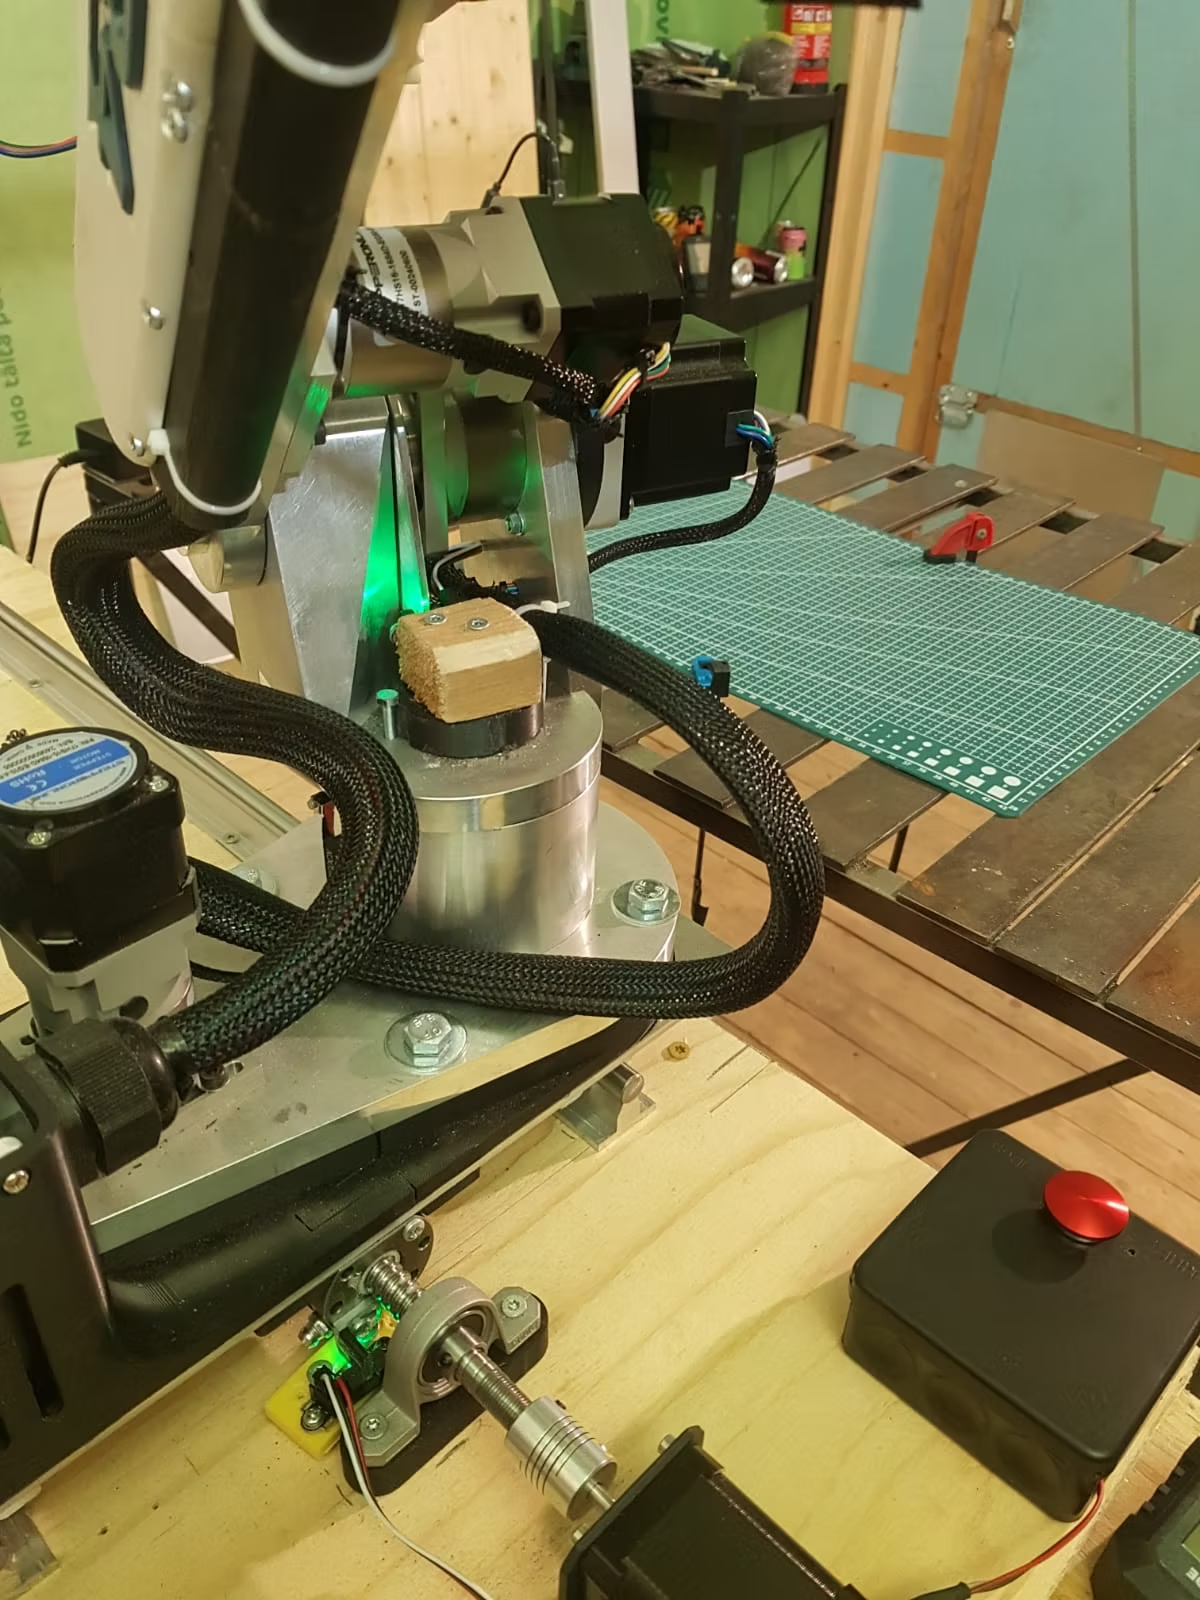
For anyone interested, here's what the newest velocity control implementation might look like in practice. It allows for over 10 times faster acceleration amd velocity than the original position based control, while maintaining smaller position and goal errors.
@yifeicheng is merging these new changes into his solution, see
https://anninrobotics.com/community/general-discussion/ros-2-driver-for-ar4-now-available
(Original trajectory and goal limits are 0.02)
7 replies
JannH
Hi all,
brief update. I have done work on the ROS2 solution to include a linear track, Pilz Motion Planner and velocity control (instead of the original position control) for a huge increase in speed while maintaining tolerances, among many other things.
I replaced some of the limit switches with optical switches, added a voltage and amperage display and incorporated a panic button in the code.
I'm using PlotJuggler in testing to validate the velocities, positions and accelerations, it's very helpful.