

Need more power? A upgrade guide for increasing torque in joint #3 using a Nema 23
Hi All,
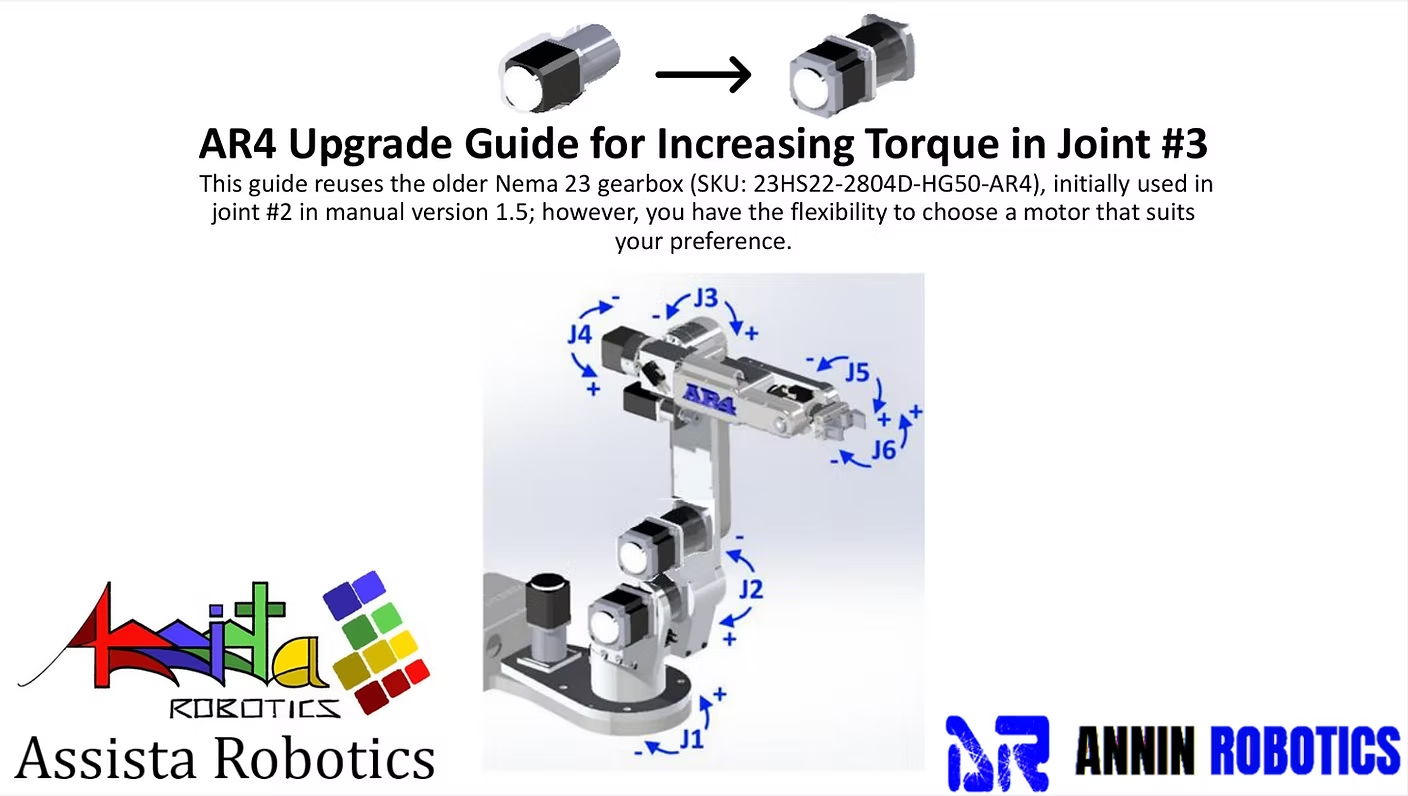
I created a guide on how to install a Nema 23 in the J3 motor position to get the most out of your robot and reuse outdated motors.
If you have any suggestions, let me know.
Cad files:
https://drive.google.com/drive/folders/1vTq5s-DdNBcjlgEjacZs7n92wS-5V-nj?usp=sharing
b6b402c6-1942-4d33-9e45-b14f201ce5a4.usrfiles.com
b6b402c6-1942-4d33-9e45-b14f201ce5a4.usrfiles.com/ugd/a7092a_ae7d38c596354986b319c3f4cd3d49a3

Hi Johann
It depends on the position of the endifector and the object. J5 creates a bottleneck at some positions, but this can be overcome in some situations.
When the arm is fully extended, the maximum payload is often limited by the joint farthest from the base (in this case, J5) due to leverage effects. If the arm is positioned with the end effector facing downwards, or if it is curled, the load is more evenly distributed, with a significant portion supported by J3, where the upgrade is beneficial. However, to achieve a consistent lifting capacity in all positions, you will need to upgrade J5 from a nema 17 to a nema 23 and make a new motor bracket, and if J4 rotation is important while holding a heavy object, you will need to upgrade that motor too
4 replies
Johann Voigtlander
Does this increase the payload at all? How much can you lift with this upgrade?