
Teensy + A6 servo Ac , encoder problem
Hi everyone.
I’d like to build a custom robot using AC servos based on the AR4 software.
For a start, I’m trying to get a StepperOnline A6 servo driver to work with a Teensy board.
The servo movement works fine, but I can’t get the encoder A and B outputs connected — every time I try, the communication between the Teensy and the PC drops out.
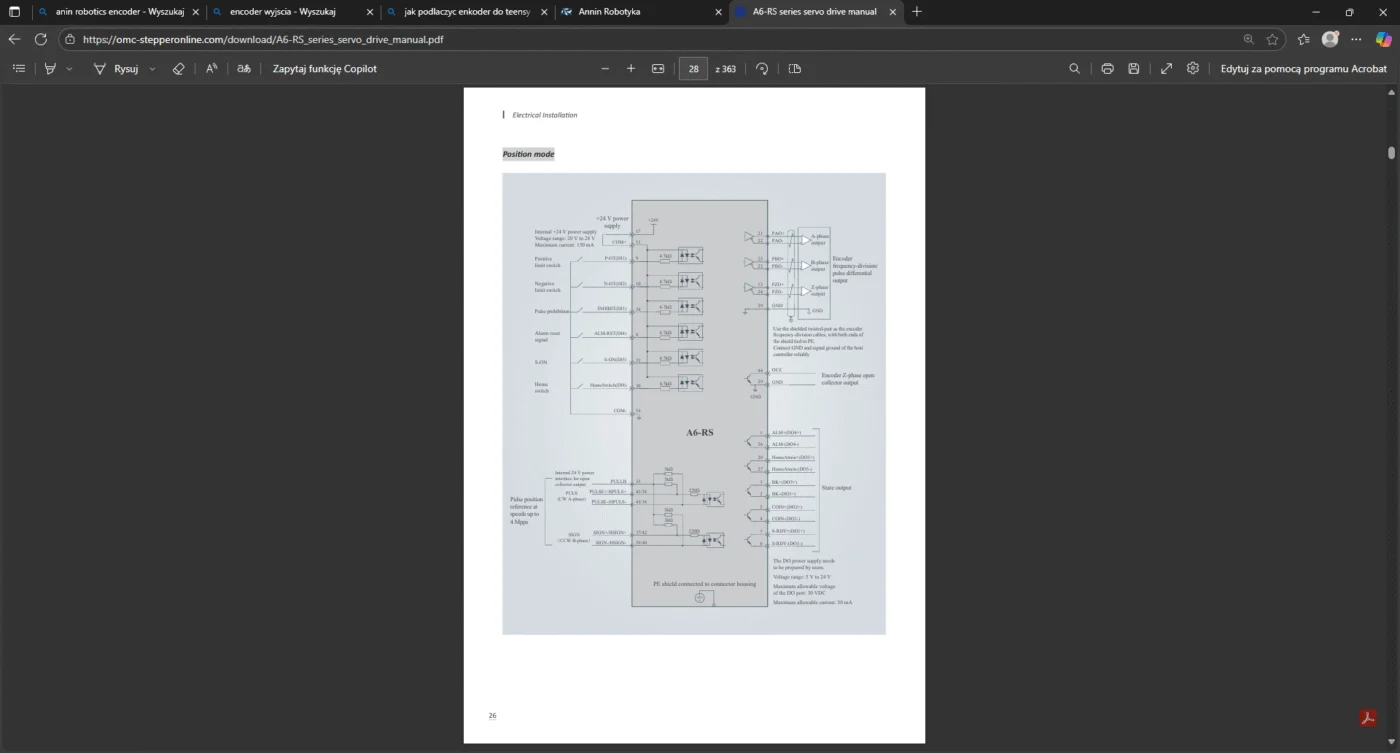

OK, I’ve analyzed it carefully, and the servo driver outputs symmetrical differential signals, while the Teensy requires TTL signals.
So I have two options:
- Servo driver → converter → Teensy
- Force the GUI to query the servo position via Modbus (the logic would need to report the position from the Teensy, compare both values, recalculate after homing, and display the result in the main application).
What do you think about that Chris Annin ?