

Hi, where can I get this thing?
Thanks

Hi Annin Robotics Community,
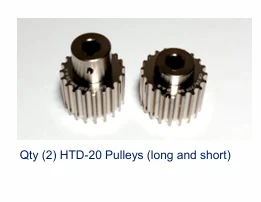
i am building AR4-MK3 i am not able find this part Qty (2) HTD-20 Pulleys (long and short)can you share the dimensions , So i can alter the available one

I can't seem to figure out how to work spline movements in the GUI. I'm sure the information is hidden away in a resource or video somewhere, but I can't seem to find any immediate information on it. Could anyone help me out?

Hi. I just saw the release of MK4 and it appears to fix the three main issues I have with my Mk3...
- J5 limit switch mechanism unreliable and creeps over time.
- Encoders have to be disabled as constant false warnings. New version seems to use some protective tape?
- Enclosure bigger and a separate power rail terminal block. Avoid having to squash a bundle of soldered wires under a screw terminal.
I'd love to upgrade my MK3 with these updates, has anyone had a look at how this is possible? Re-doing the wiring will be unpleasant but I think will bring long-term reliability.
Is it possible to remove the robot from the enclosure, feed out all the wires and reconnect it or will I have many issues with wires not reaching?
Many thanks, Alastair

I've just completed assembly AR4 and startup commissioning step by step. I've checked all motor rotation, direction, limit switches. All are working fine. Then, I checked Calibration each joint individually from J1 to J6 and all of them could move without problem.
Until i pressed Auto Calibration, J1, J1, J3 could set home completely, and then J4 rotate untit it touched limit switch. From that moment, 24V supply just suddenly no output (green LED on the power supply adapter was gone). I removed power supply to check it without load, it was really broken.
I think problem might me because the J4 limit switch wire was pulled until it touched the robot chassis and caused the short circuit which i'll try to fix it before I power up with the new power supply.
One more thing, i feel the 24V fan has really loud noise. I think it's because the fan ventilate step motor drive which are packed up in limited space. This might not be a big problem but more or less, i think fan is working high load which may cause the high current for 24V.
I'm ordering Meanwell switching power supply LRS-350-24 to replace and will add a 7.5 Amp 24VDC fuse before supply power to robot. Do you think this will help protection better? If you have any recommendation for this problem would be appreciate.
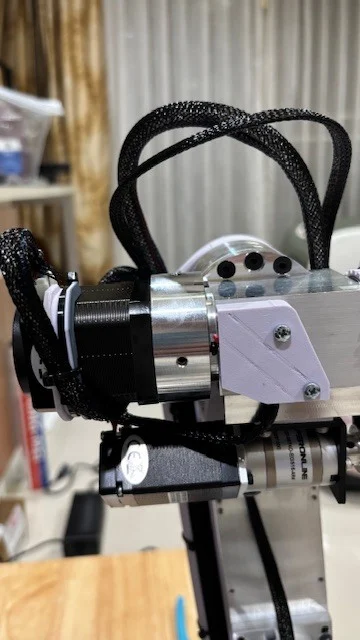
Note: below photo show the last position of the J4 limit switch before power supply was broken.
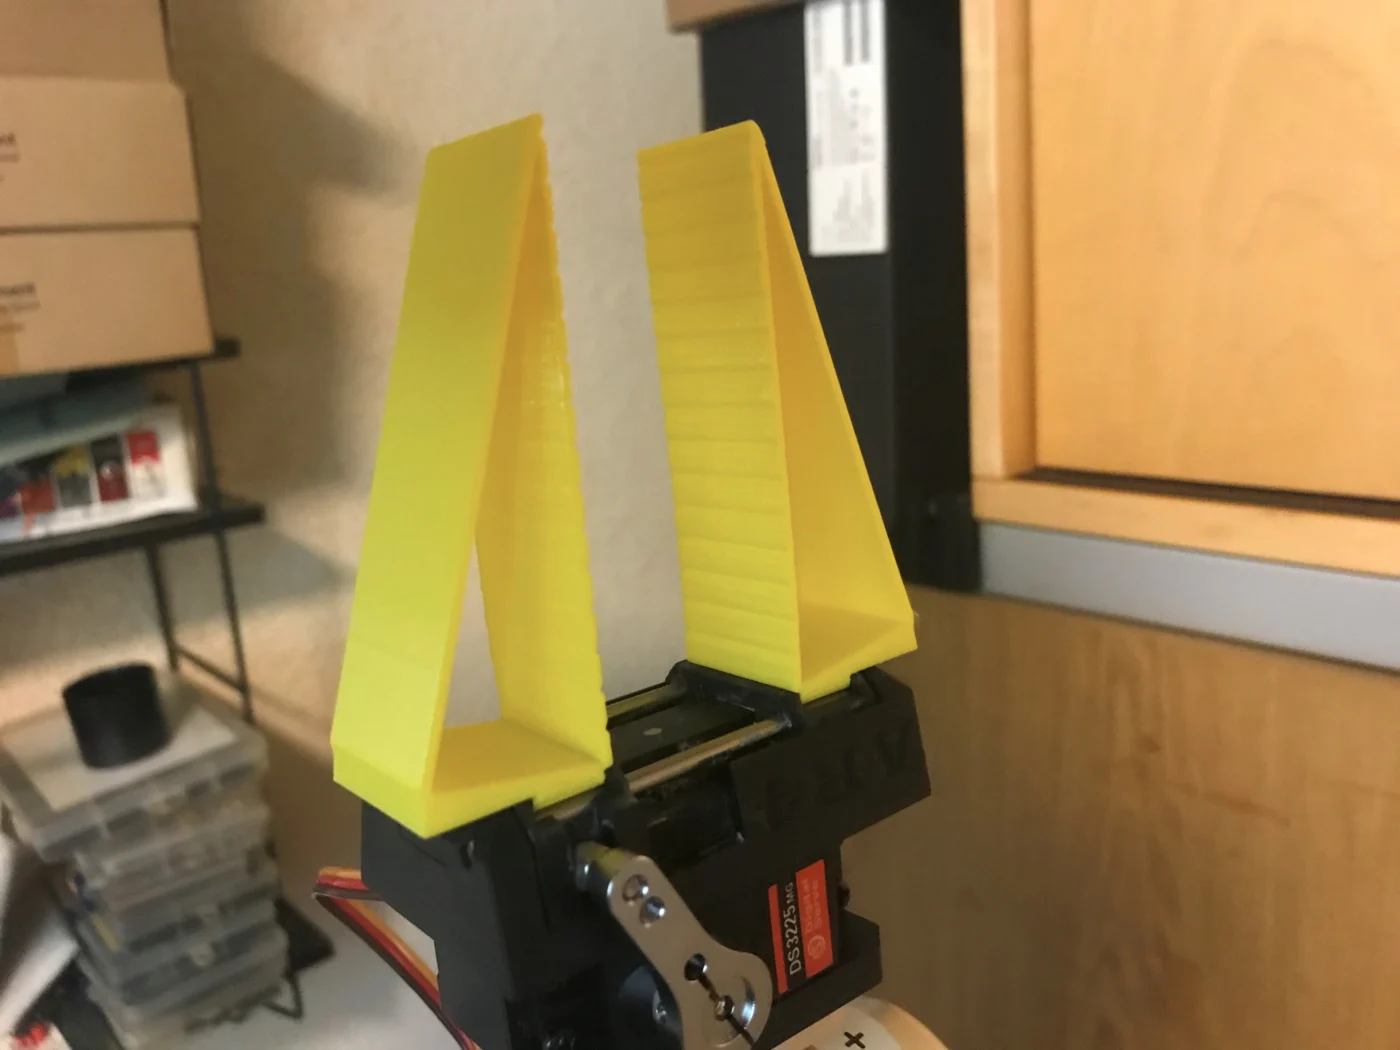
If somebody needs Gripper for the Servo AR4. 3D printed 2 Versions.
Picture shows big Version.
The Grippers can be exchanged
3fm Files for Bambu X1C
Available by Makerworld
Greifer für AR4 MK3 Servo – Kostenloses 3D-Druckmodell – MakerWorld

I’m seeing excessive backlash in the shoulder joint of my new AR4-MK3.
Motor/gearbox: 23HS22-2804D-YGS50-AR4, 50:1 planetary.
Spec lists backlash ≤15 arc-min (~0.25°).
Measured backlash at the shoulder joint is ~0.6° total on direction reversal. All external fasteners, hubs, and couplers, internal threads are tight, and the backlash remains with load removed, so it appears internal to the gearbox.
Is this amount normal in practice? Are these gearboxes serviceable (preload, shims, bearings), or is replacement the only option? Any known wear or failure modes?
Is there a disassembly document on the Gear-Box to review internal components?
Thanks, Mech

Hi everyone,
I just completed my Annin AR4-MK3 (the assembly instructions and part kits were excellent), powered it on, and began the startup procedures. Everything appeared to be working, and each motor moved appropriately. However, after about fifteen minutes, the control software hung. I restarted everything only to find that the Teensy was dead (it wasn't detected by my computer, didn't light up, and its chip got very hot while connected to power).
Using a multimeter, I determined that there was a short on the Teensy between the Teensy's 3.3v pin and ground pin (resistance of about 4 ohm). I checked the AR4's wiring and everything appears to be correct with good connections. I also confirmed that there was not a short between the 5v line and any of the signal pins or ground.
Any suggestions for a next step in finding the cause of this issue would be greatly appreciated. I have access to a multimeter, an oscilloscope, and a benchtop power supply. And a couple of new Teensys are on their way.
Thanks!
--Chris

Hey Team,
I swapped out my Arduino Nano for an Arduino Nano ESP32 (drop-in replacement).
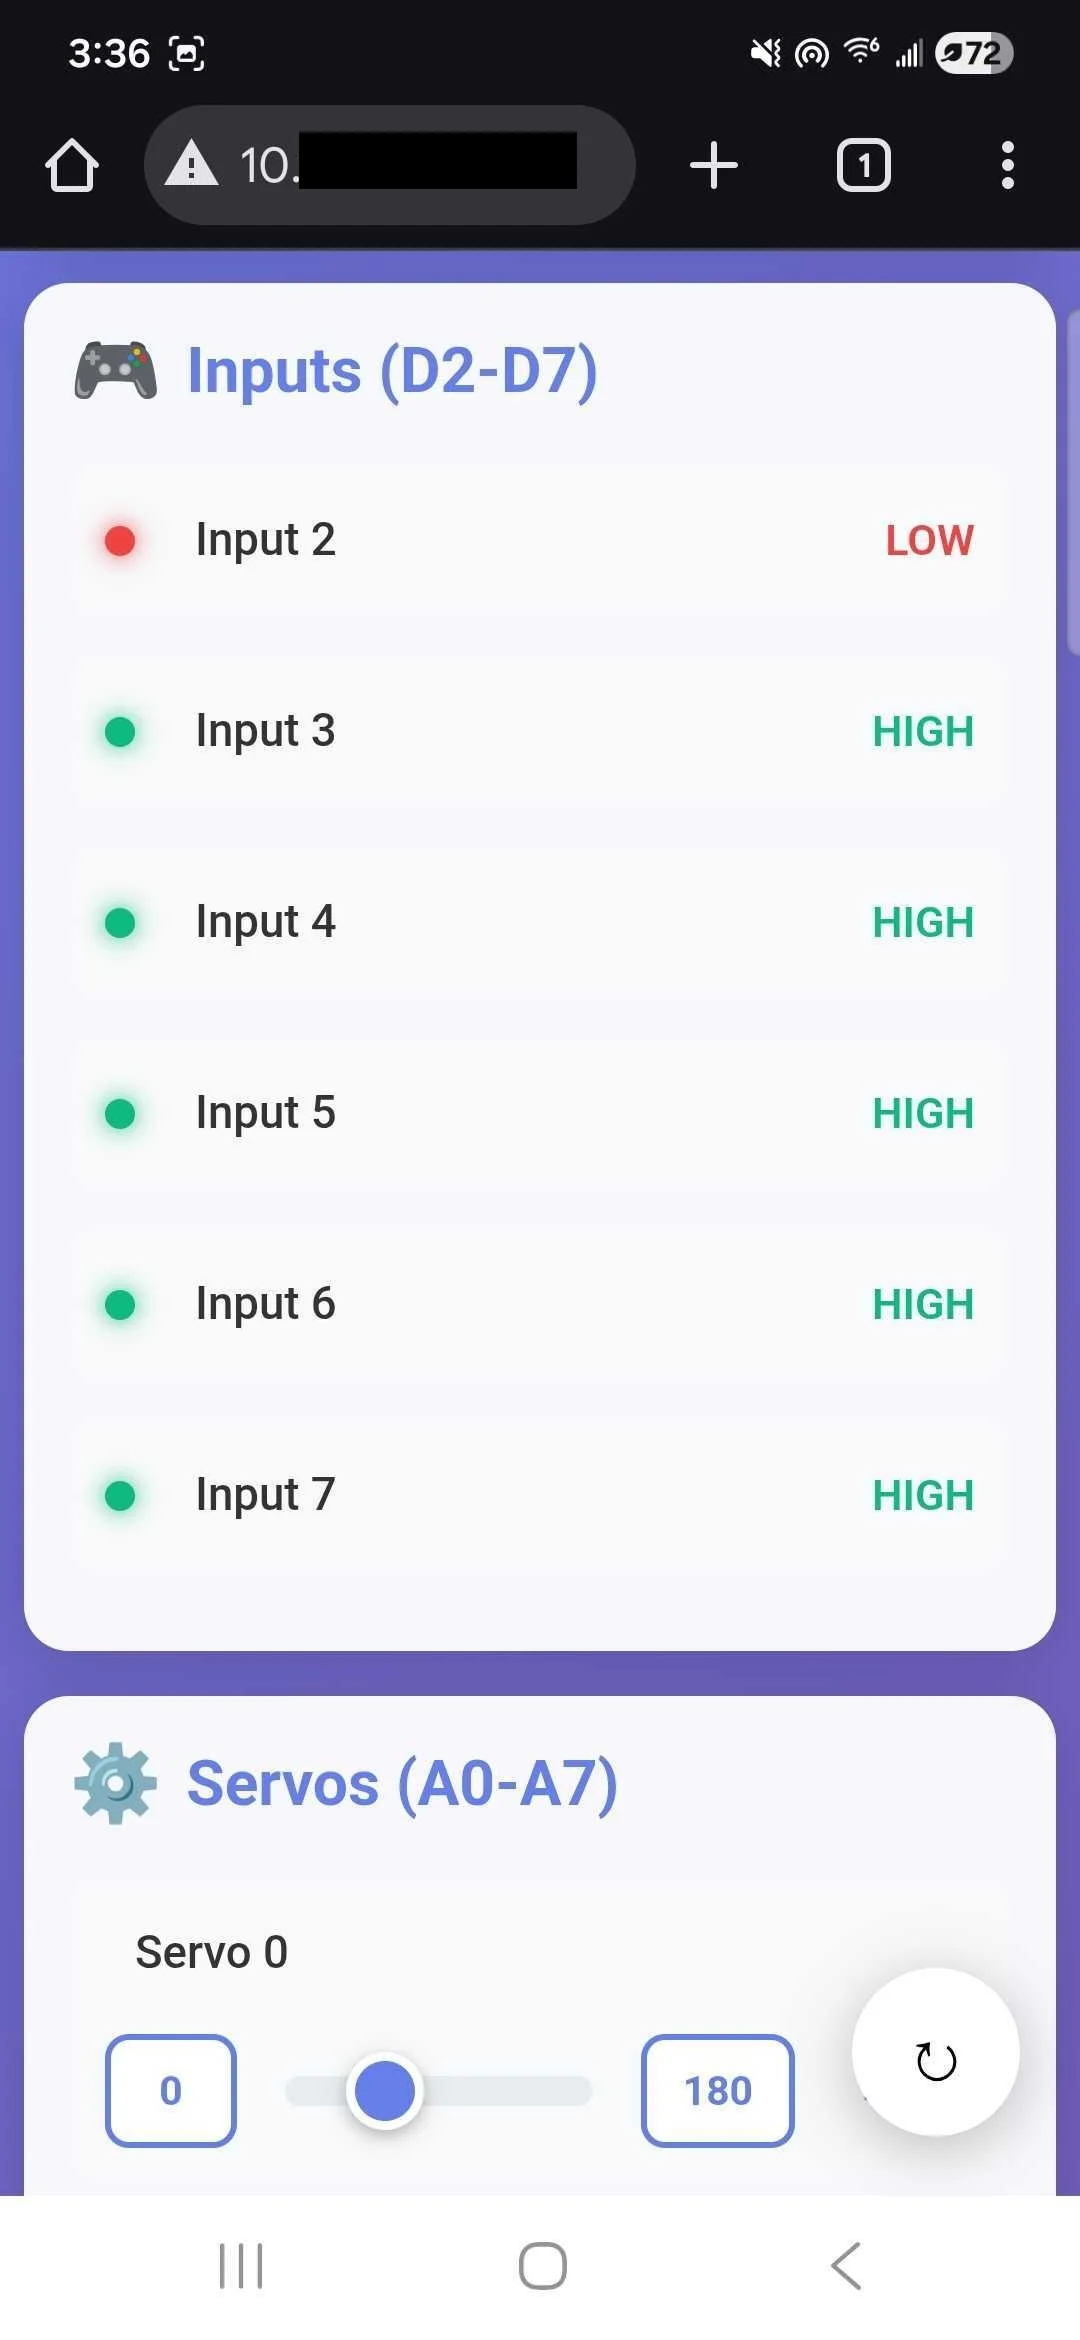
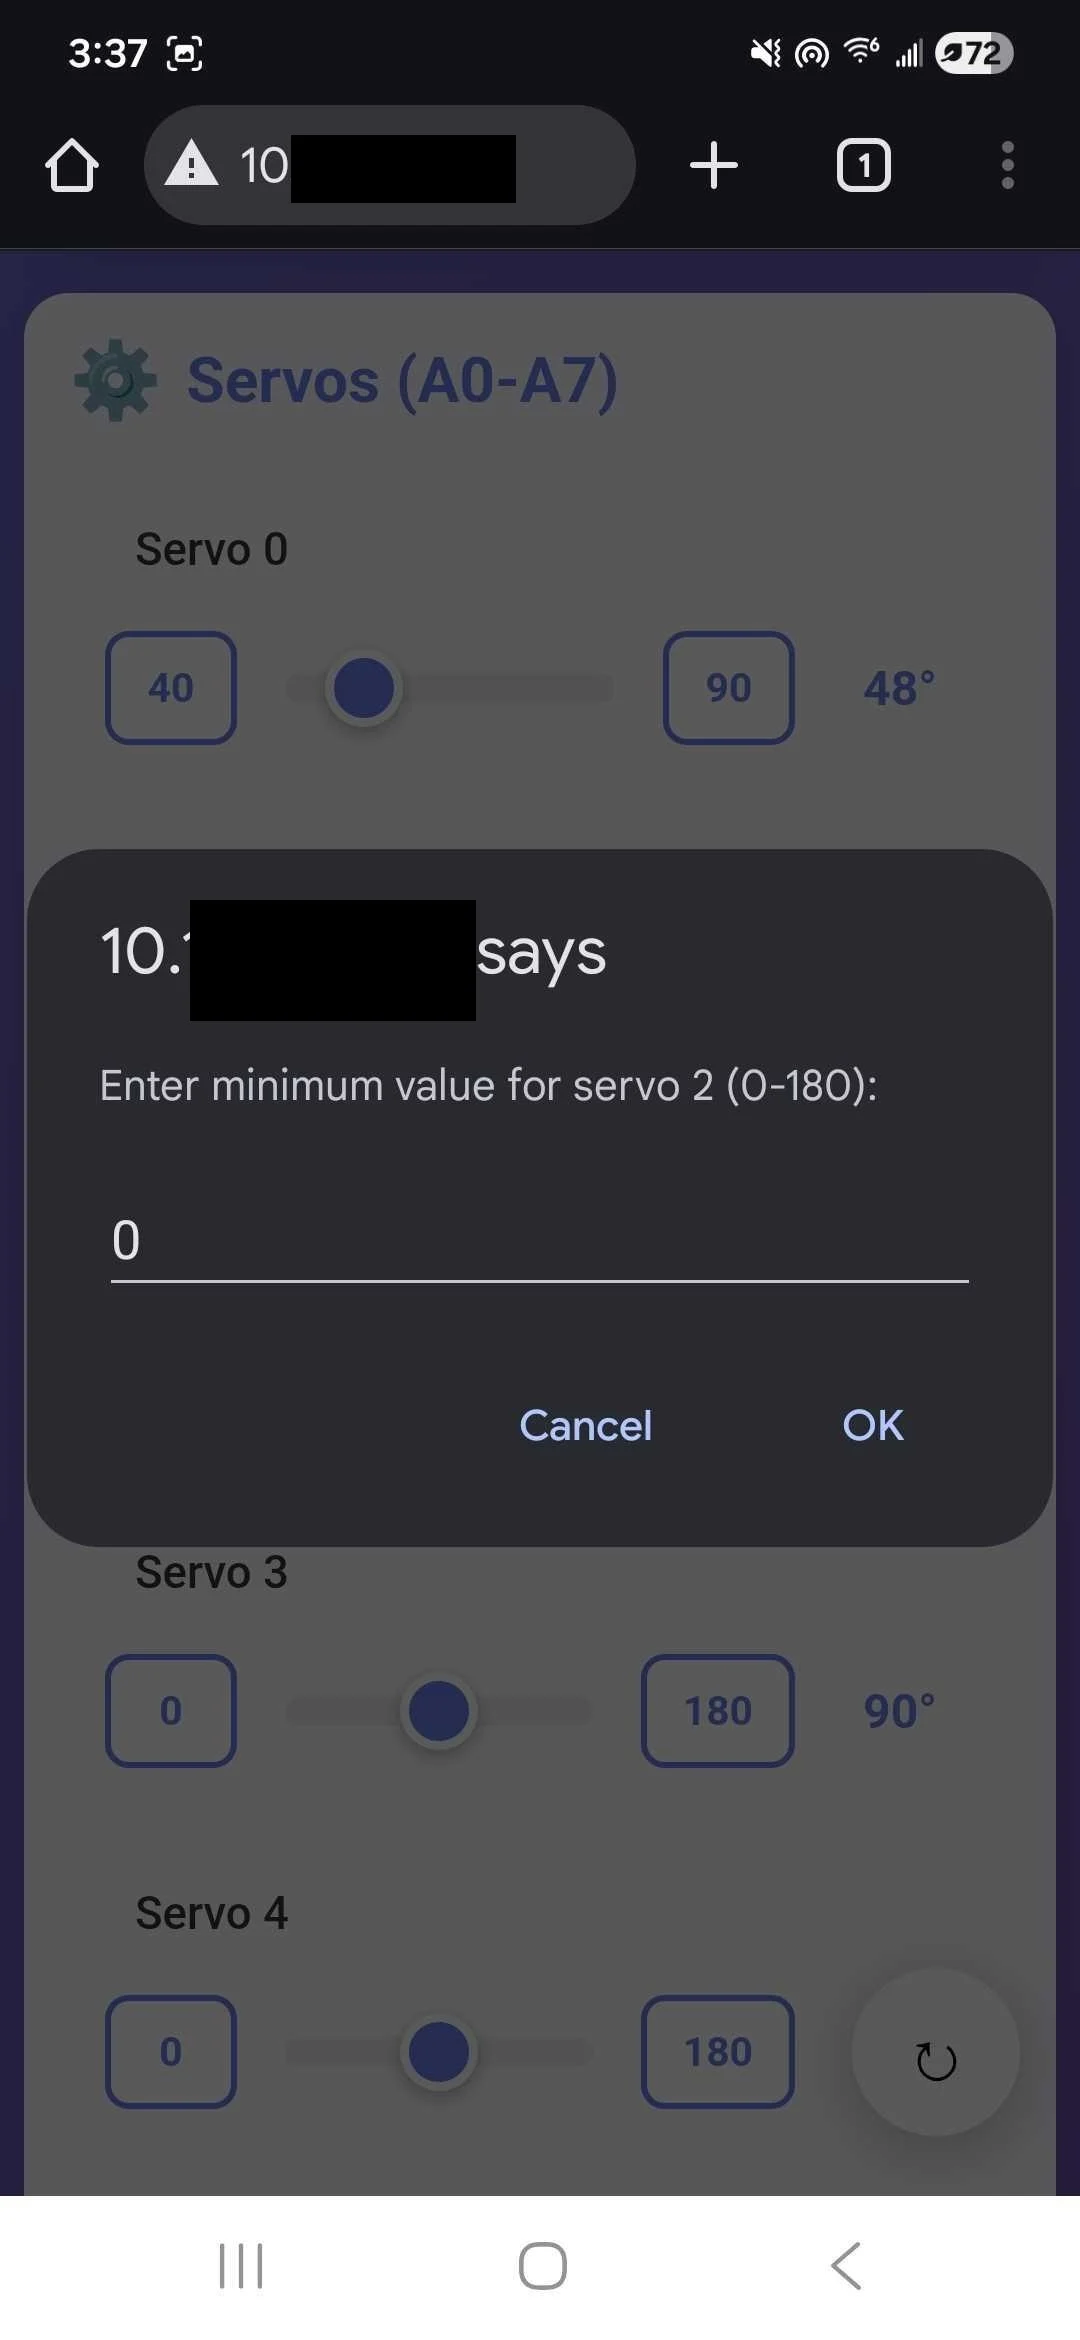
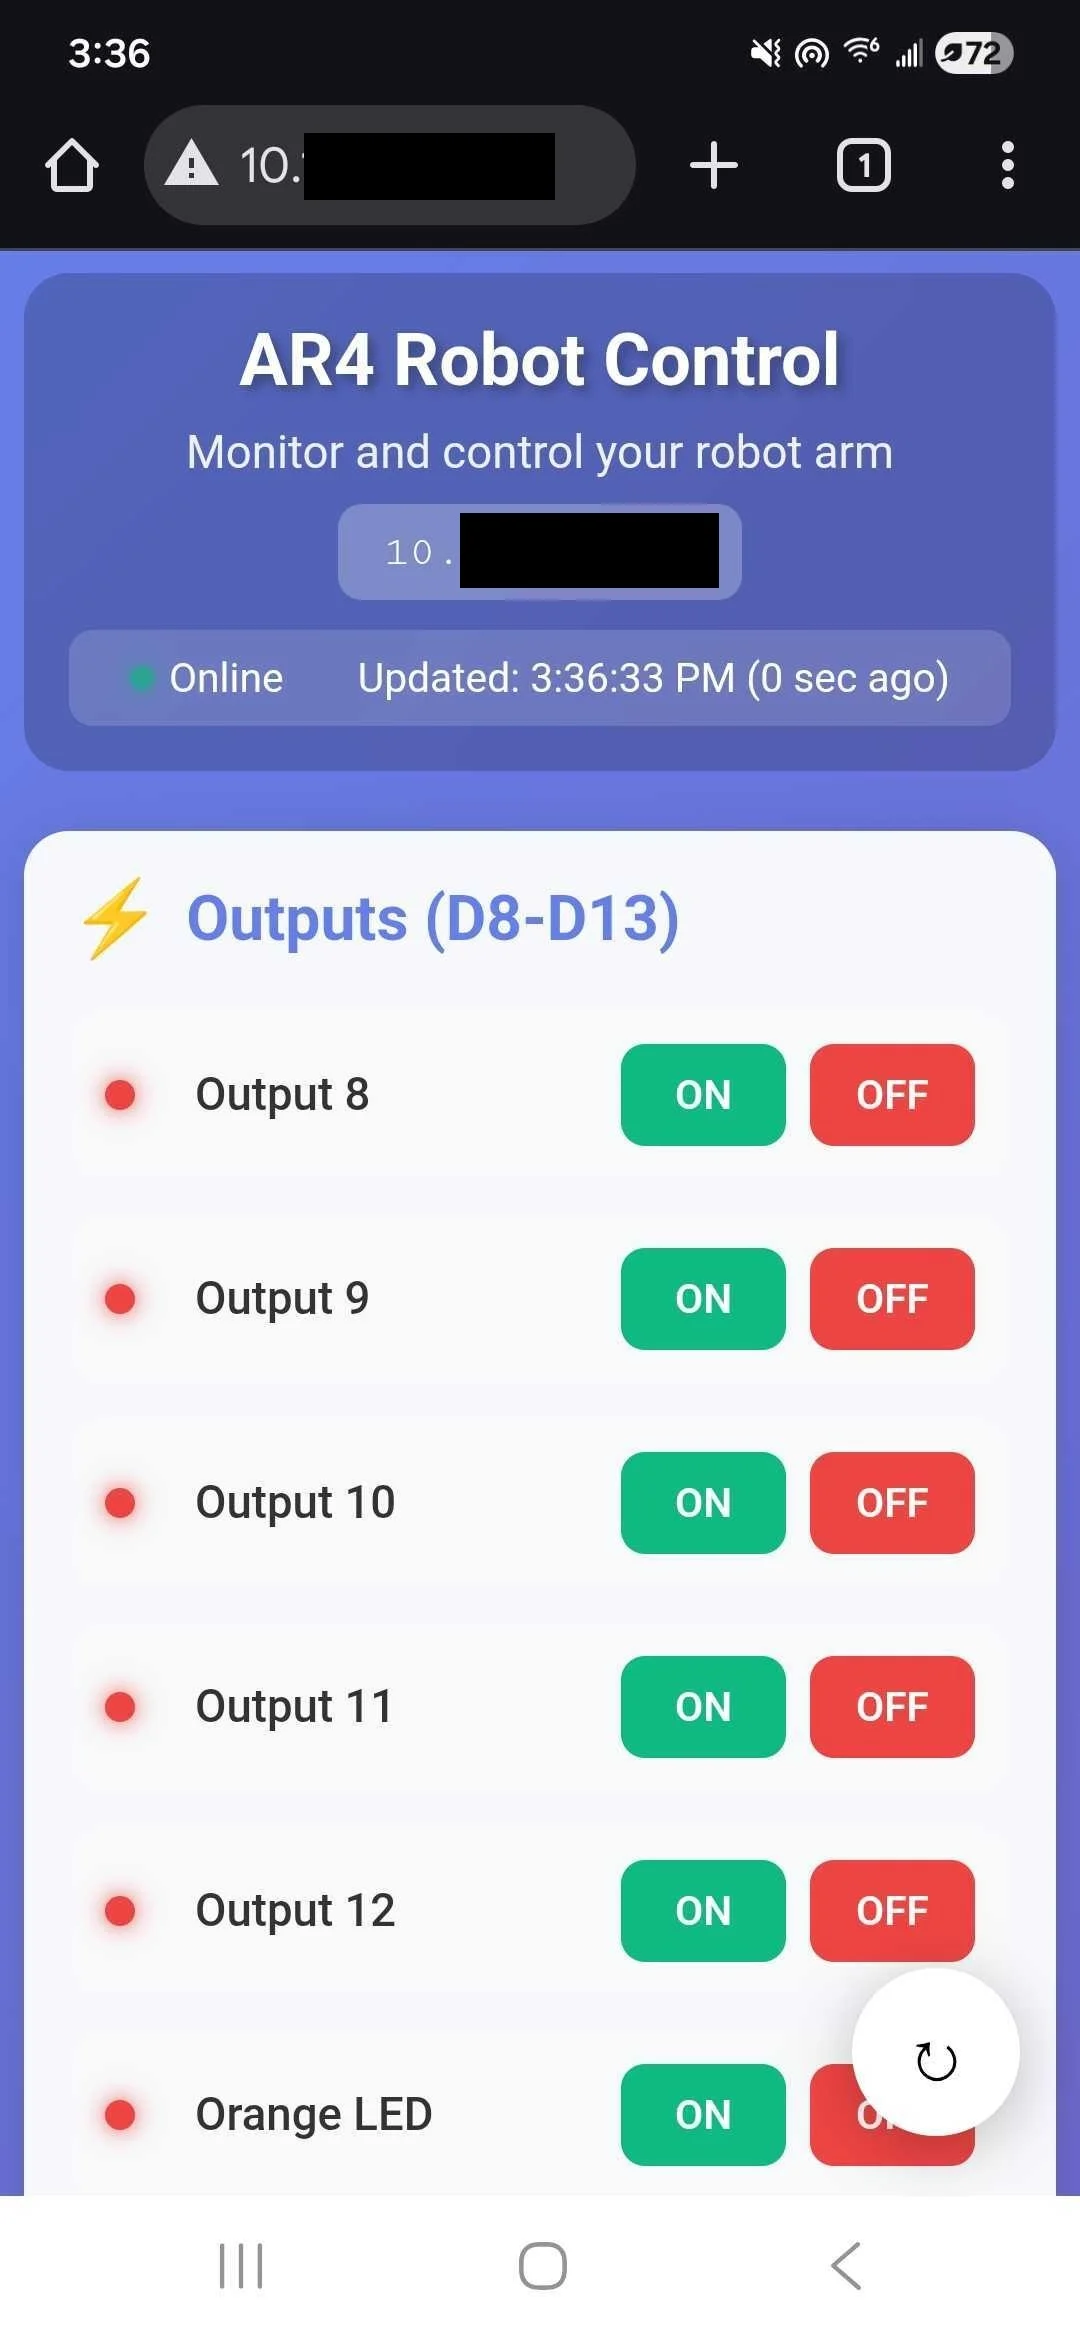
It will now connect to wifi and create a webpage showing input/output/servo states.
You can rename the input/output/servos to whatever you like, and you can toggle outputs on or off on the webpage.
I still need to do some testing, but it should retain all functionality of the original Arduino Nano code
I developed this mostly for a "wifi button."
Cheers

I was hoping to make my own wooden box for the AR3 robotic arm rather than the BUD Industries box that is recommended for the project. Is that possible? Would it be possible to use a standard storage box too? I ask because the price difference makes me think there is an important distinction in material that matters for the functionality of the robot.