

Some issues with calibration consistency were brought to my attention.
The debounce timer I implemented a couple of revisions back was likely pulsing the motors during the entire 3 ms debounce window. I've updated the calibration debounce logic as well as the distance and timing on the double press.
If you have had any issues please upload sketch 6.7.1 from the MK4 downloads page (please continue to use the 6.7 exe file - no update on the exe, only the sketch).
Please keep me posted as soon as possible with any and all feedback on this issue. Thank you.
Hello everyone,
With the recent changes in U.S. tariff policy, I’ve worked with StepperOnline to bring the gearmotor and driver kit prices back down, and I’ve also reduced the AR4 robot kit prices to their pre-tariff levels.
That means the total cost to build an AR4 robot is now back to around $1,900.
My goal has always been to make the AR4 an affordable, capable robot arm for everyone - an aluminum-frame, repeatable 6-axis robot with a 5 lb payload, open-source software, and full build instructions, all at a price that makes robotics accessible to more people.
Thanks to everyone in the community for your continued support.
I’ve been running into some issues with the Linux version of the software, mainly related to library compatibility. During the setup and execution process, I keep getting errors that seem to point to missing or incompatible dependencies.
What’s more confusing is that even ChatGPT flagged a specific compatibility problem involving a .pyd file. As far as I understand, .pyd files are Python extension modules compiled for Windows, not Linux. So it seems like the software package might include Windows-specific components that don’t work properly in a Linux environment.
Because of this, the program fails to run correctly, and I’m stuck trying to figure out which libraries I should replace or how to properly adapt the environment for Linux.
Has anyone experienced something similar or knows how to handle cross-platform Python extension issues like this? Any guidance would be greatly appreciated.
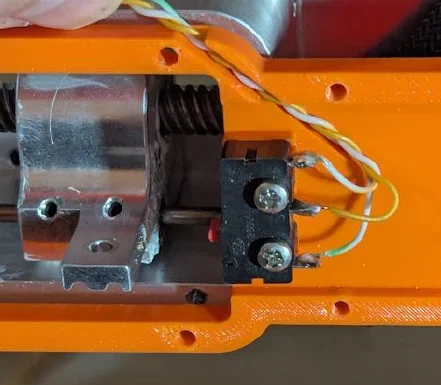
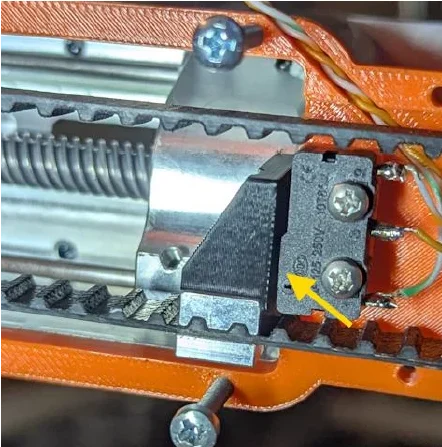
Hey everyone - I updated the J5 limit switch. Its no longer the roller tip switch mounted in the arm. The update has a 10T85 switch mounted inside the side cover. This should make installation easier and have improved performance. To update you just need to print the new side cover and then re-route your J5 wires to the new location. Check out the latest build manual version 1.7 for all the details.
We've released a new update for our AR4 robot arm.
Software version 6.3 now includes native Linux support and a redesigned, resizable interface.
Alongside this update, I've added an ROS 2 page on the website featuring two community GitHub repositories from Yifei Cheng and Ekumen Labs.
Thank you to Jason Kirk for helping with the Linux updates.
You can follow us at Annin Robotics on LinkedIn.
The AR4 community has been sharing a variety of 6-axis robot arm projects from their workshops, classrooms, and labs.
This video highlights some of those builds and shows where you can post your own project to share with the community.
Post your build here: https://anninrobotics.com/user-builds/
Hi everyone, for those building an AR4 without a 3D printer, you can now purchase all the printed parts directly from my partner, CI Printing. This includes clear covers as well.
I've set this up as a direct service with no markup from me, just to give you the option.
Link to the pre-printed parts are here at the bottom of page: https://anninrobotics.com/robot-kits/
Hi everyone,
We uploaded a new robot programming tutorial all in one video and have also set this up as a course that you can take at your own pace.
Link to Course ---> https://anninrobotics.com/community/course/ar4-robot-programming/lessons
Hello everyone,
I’m excited to announce the release of software version 6.1. This update includes several important improvements to robot performance and calibration:
- Enhanced acceleration and deceleration curves – Motion profiles are now smoother and more refined for improved robot control.
- Updated motor driver microstep settings – These changes not only complement the new accel/decel curves but also improve overall motion smoothness.
- Driver DIP switch update required – When upgrading to version 6.1, please update your motor driver DIP switch settings. Refer to the latest robot build manual (version 1.6), page 230 for the new settings. For users running earlier software versions, the previous DIP settings are still included on page 231 for reference.
- Improved calibration routine – Includes updated debounce logic to reduce calibration errors and prevent “calibration failure” messages.
Please download the updated manual and review the changes before installing the new version. As always, if you encounter any bugs or issues, let me know and I’ll work quickly to resolve them.
Thanks for your continued support, and I hope you enjoy the improvements in version 6.1!
Hey everyone!
Version 6.0 is here, featuring a virtual robot (digital twin) for offline programming and simulation. Jog, program, and test movements in a virtual interface before running them on the real robot.