


My AR4 is driven by six stepper motors, can I control it using only a computer and Arduino mega2560 without using Teensy? If possible, can we use the AR4 HMI interface?
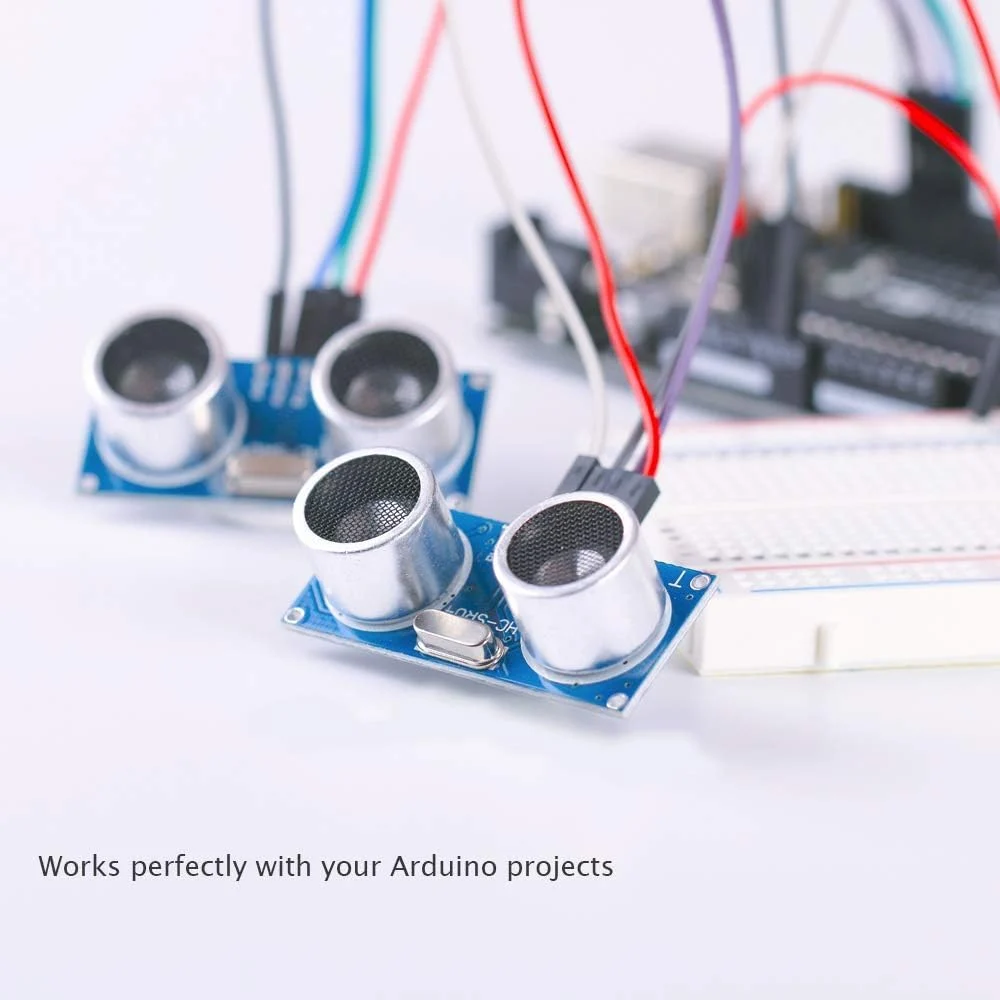
I'm wanting to use an ultrasonic module for location as my target will change height. This is what I have, they have a trigger and an echo for the signal. From what I have been able to surmise, there is a short burst on the trigger followed by a listening time for the echo. The time from the trigger to the echo gives the distance, so this should be an analog sensor. With the controller software I only read about digital sensors and all analog is used for servo motors. Is there a way to use this sensor? I could write an additional Arduino code, but I don't know how to get the software to use it.

Hey Team,
It took me awhile to get the camera to open in linux. I had to modify ARconfig.json with my webcam name:
Original:
"VisProg": "USB 2.0 Webcam",
"curCam": "USB 2.0 Webcam",
Modified:
"VisProg": "HD Pro Webcam C920",
"curCam": "HD Pro Webcam C920",
Just posting so others will save time.
6.31 Many improvements have been made.
The menu truncation issue has been resolved.
The coordinate disappearance issue after returning to the origin has been resolved.
The ability to save machine data to a custom robot is really great.
It seems like the robot can't return to the origin in one go.
Thank you so much for the stable controller.
Hi Chris,
I've chosen the way to print the structural components for my AR4. And as the manual says "The J4 tube cannot be 3D printed", so I need to make it. Unfortunately, I can't find in the manual the exact sizes or technical drawing of the shaft for me to cut it and drill the holes.
I checked the stl model (J4 Main Shaft.STL), it looks like 25,4 mm outside diameter, 3mm thickness and 116,3mm length.
So I suppose the standard 25mm aluminium tube will work too, right? Can you please confirm the sizes and the holes positions?

I messed up the 3mm ID bronze bushings when trying to put it into the J5 Carrier. Is there any supplier of these bushings where I can get more of them? I can't seem to find them online.

If the encoder is powered with 5 V and its output high level is also 5 V, how should it be connected to a 3.3 V microcontroller such as a Teensy 4.1 without causing damage?
Do you recommend powering the encoder at 3.3 V instead, or is there any internal protection or differential receiver requirement for safe connection?

Dear Annin,
I really love the work you did with all the free software and math you give to us. I built a 3 DOF robotic arm and i'm using your software moving the joints. Actually, i'm using the AR2 software for the Arduino Mega. I wanted to know if it is better to move to the AR4 software in my case, because i just see that have significantly changes for the 6 axis arms. Also, i wanted to know if with your software, i can make lineal moves with my 3 DOF arm.
Best regards,
Leo

Hi everyone!
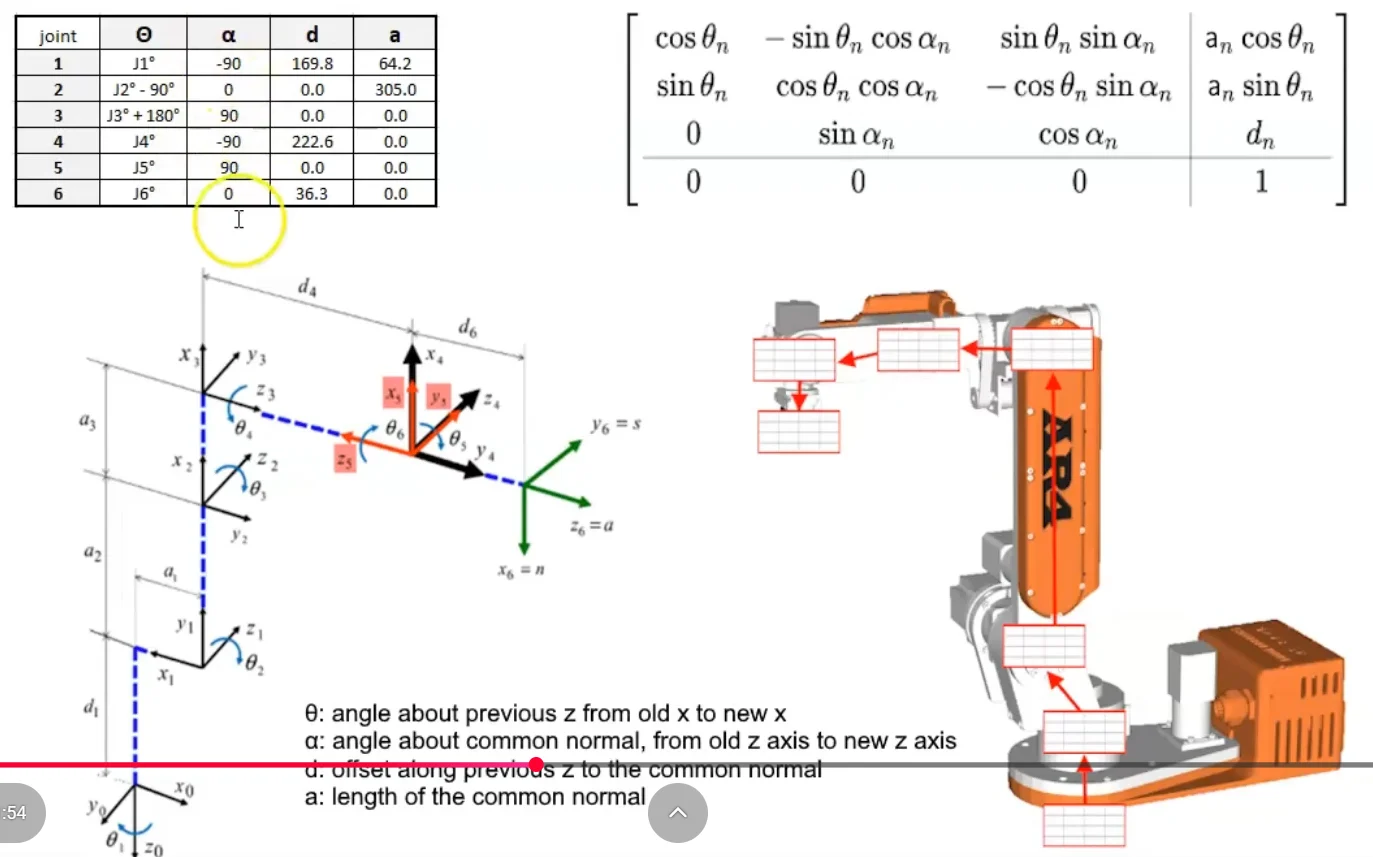
I'm really confusing with the D-H table. Can you enlighten me how theta offset works and why alpha_3 is 90 degree instead of -90 (since alpha_3 is angle about common normal x3 from z2 to z3)?
Thank you so much!
This feature would be great.
The AR4 robot has an SD card, so I could load a specific program (like a 3D printer) onto the SD card.
I could attach a button to the Teensy4.1 board, and when I press the button, I could load a program to repeat the task onto the AR4.
Wouldn't it be difficult to read a file from the SD card and have it repeat the task without a computer?
I could attach a screen to an Arduino Mega and use it to transfer files.
It's a shame that the robot itself doesn't have features coded to allow it to operate without a computer.
The Teensy4.1 board can use IP, but it's a shame that it uses USB for communication. USB is susceptible to noise.