

This is what I did with my AR4 for halloween.

Hello, I have a question.
Is there a parameter in the Teensy code that allows me to change the axis speed?
I’m fine-tuning the arm control using AC servos, and I don’t want to reduce the servo resolution.
With 1000 imp/rev on the motor, I’m not getting a satisfactory angular speed on the arm with a 1:100 gear ratio.
What is the step pulse frequency (STEP signal frequency)?
Hi everyone.
I’d like to build a custom robot using AC servos based on the AR4 software.
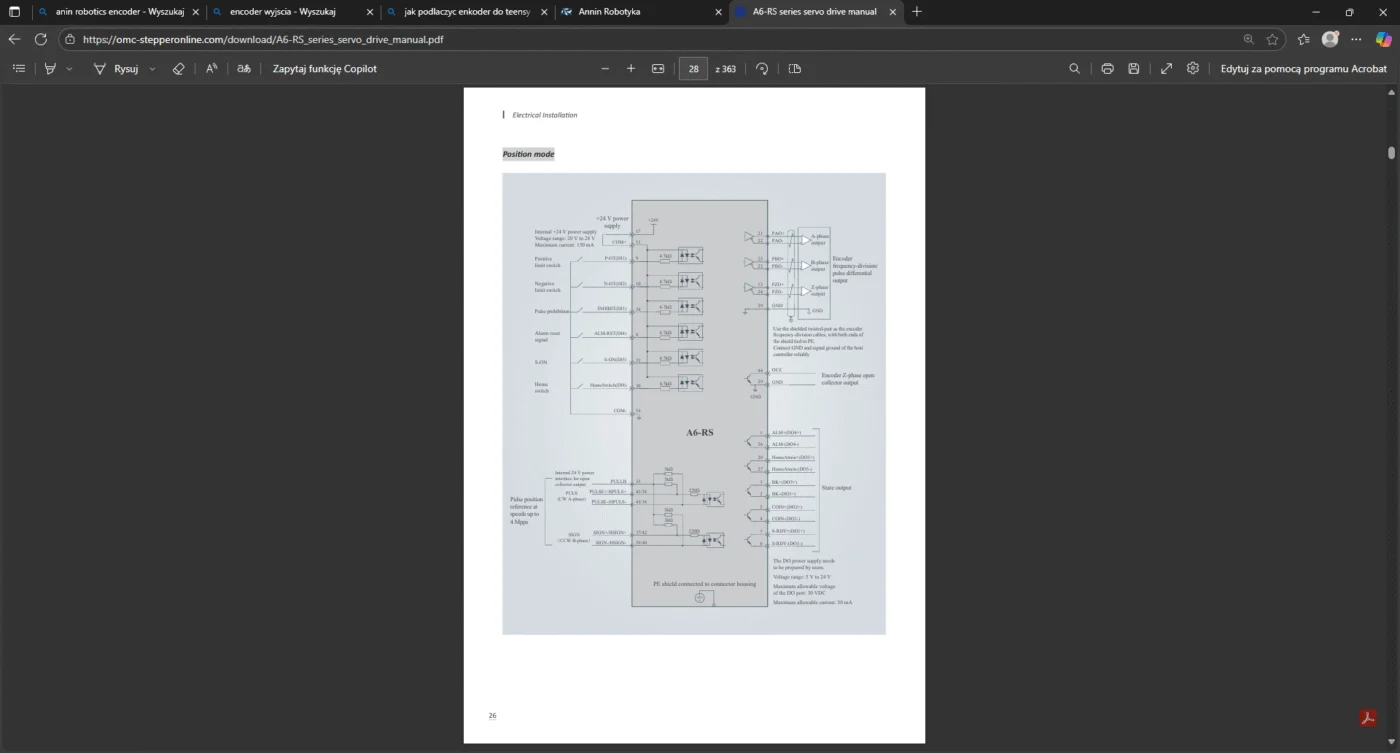
For a start, I’m trying to get a StepperOnline A6 servo driver to work with a Teensy board.
The servo movement works fine, but I can’t get the encoder A and B outputs connected — every time I try, the communication between the Teensy and the PC drops out.
Check out this 7th-axis linear track someone built for the AR4.

Hi everyone! I'm building a 3D printer and I'm planning to buy a stepper motor online from https://www.skysmotor.co.uk. What models (e.g., NEMA 17) do you recommend for the X/Y/Z axes? Is it better to buy pre-wired cables or separate cables? Also, how can I check compatibility with Arduino/RAMPS-type boards? Any tips would be greatly appreciated!
AR4 robot drawing an elephant
Putting Benchy into box.
AR4 robot arm build, using CAN Controlled Closed Loop Controllers.
First run of the Annin AR4 testing airflow from a Noctua Fan
Using an xbox controller to teleoperate a Annin Robotics AR4 robot arm. Motion planning is handled by the moveit_servo package which generates continuous real-time velocity trajectories.
Code: https://github.com/ycheng517/ar4_ros_driver_examples AR4 ROS driver: https://github.com/ycheng517/ar4_ros_driver