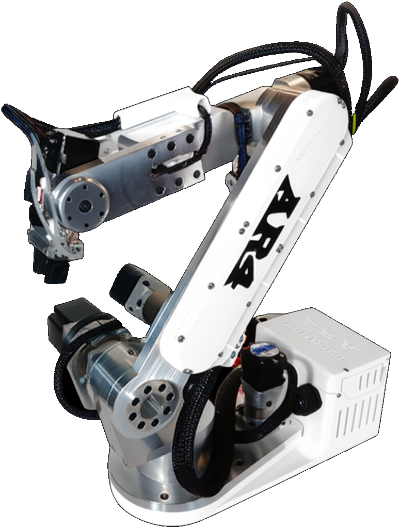
Teleoperates an Annin AR4 for tabletop manipulation using the UMI inte
Budget UMI Teleop Retrofit on Annin AR4
Di adapted the Universal Manipulation Interface (UMI) stack onto a low-cost Annin AR4 with a custom 3D-printed servo gripper and a consumer fisheye camera. The video shows external and eye-in-hand views of the arm performing tabletop manipulation. Open-source retrofit code is on GitHub for makers chasing affordable imitation-learning / teleop research.