
Revision guide
AR3 vs AR4 (and MK4 vs MK5): What Changed
The Annin robot arm has been refined in public for years. Here is what changed at each step, from the AR2 to the current AR4-MK5, and what it means if you own an older arm.
Current design
The AR4-MK5 is the current revision: Hall effect homing on J1 to J3, a new build manual and full DH kinematic sheets. In Chris Annin's words, the software keeps moving; the arm is done.
Current
AR4-MK5
Controller
Teensy 4.1
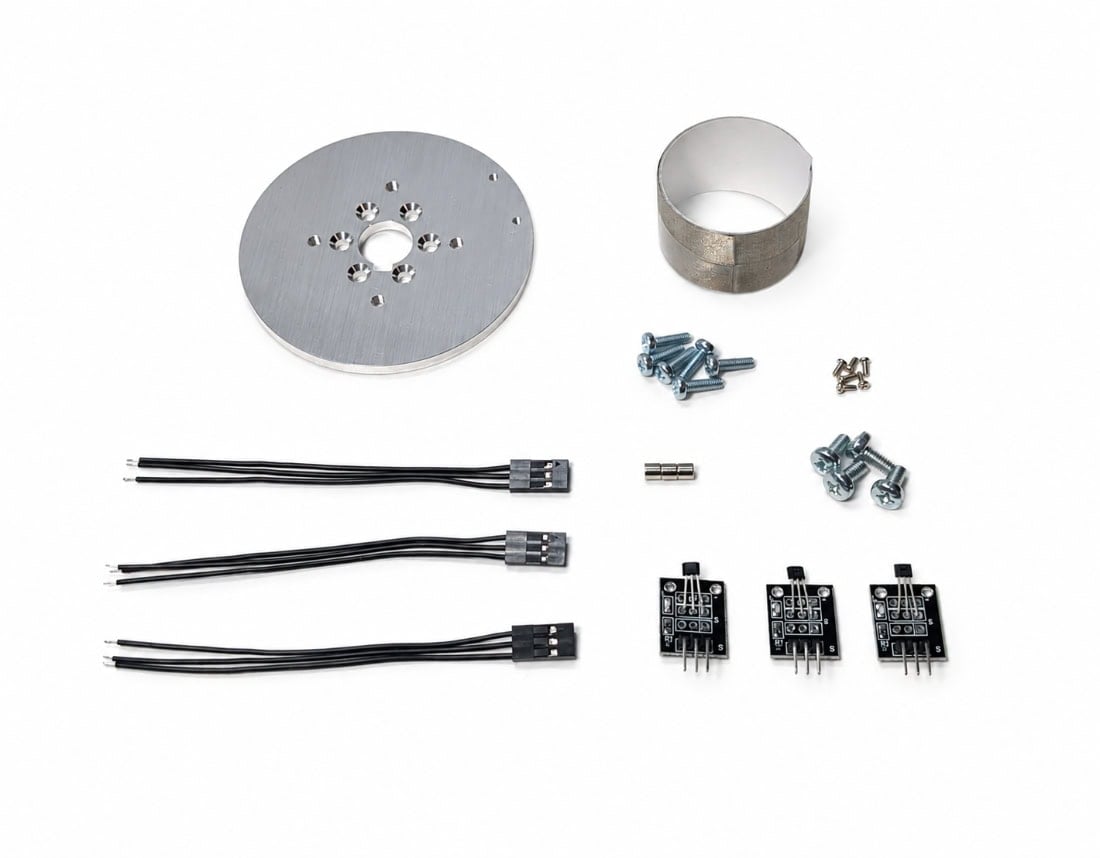
Hall upgrade
$42.50
HTD J3 update
$32.50
AR3 vs AR4: the big change
The AR3 closed the loop by adding CUI encoders to dual shaft stepper motors, driven from a Teensy 3.5. The first AR4 (MK1) switched to a Teensy 4.1 and to motors with integrated encoders, replacing the add-on CUIs. Every AR4 since builds on that base.
| Controller | AR3: Teensy 3.5. AR4: Teensy 4.1 |
|---|---|
| Encoders | AR3: add-on CUI encoders on dual shaft motors. AR4: encoders integrated in the motors |
| J3 drive | AR3: L-series belt. AR4 (MK3 on): HTD belt |
| Electronics | AR3: separate enclosure. AR4 (MK2 on): in the base |
| Homing (MK5) | Hall effect sensors on J1 to J3, microswitches on J4 to J6 |
Every revision, AR2 to MK5
AR2
First major release. Open-loop steppers, Arduino Mega, external enclosure, chain-and-sprocket on J3.
AR3
Teensy 3.5, CUI encoders for closed loop, dual-shaft motors, L-series belt on J3.
AR4-MK1
Teensy 4.1. Integrated motor encoders replace the add-on CUIs.
AR4-MK2
Electronics move into the base. Smaller DM332T drives. EG-series gearmotors on J1–J3.
AR4-MK3
EG motors on J4 and J6. HTD belt on J3. First aluminum part changes (J6 housing).
AR4-MK4
Higher-precision gearboxes and motor body changes. Dedicated upgrade path from earlier arms.
AR4-MK5
Hall-effect homing on J1–J3. New build manual and full DH kinematic sheets. Software keeps moving; the arm is done.
MK4 vs MK5
MK4 brought higher precision gearboxes and motor body changes. MK5 adds Hall effect homing on J1 to J3, plus a new build manual and full DH sheets (standard and modified) on the downloads page.
- MK3 and MK4 owners can add MK5 homing with the Hall Effect Sensor Upgrade ($42.50). Print the mounts from the MK4 to MK5 update manual.
- Older arms with the L-series J3 belt can move to the HTD series belt update for joint 3 ($32.50).
- Use the HMI and Teensy sketch that match your revision. The downloads page lists software for MK5, MK4, MK3, MK2, MK1, AR3 and AR2.
If you own an older arm
Older revisions still have their manuals and software on the downloads page. For ROS 2, the ar4_ros_driver README lists ar_model options mk1 to mk4; check the repository for MK5. For the AR3, a community ROS 2 project exists (AR3 Robotic Arm Cockpit). Ask build questions in the community.
Beware AR3 and AR4 kits sold on AliExpress and similar sites. They are counterfeits, often cannot run the latest software, and use open-loop encoders, weak drivers and gearboxes with backlash.
Kit plus motors
$1,928
Combo kit $1,229 + StepperOnline motor package $699. Grippers and printed covers are extra.
Keep reading
FAQ
What is the difference between the AR3 and AR4?
The AR3 used a Teensy 3.5 and add-on CUI encoders. The AR4 moved to a Teensy 4.1 and stepper motors with integrated encoders, then later revisions moved the electronics into the base, added gearmotors and precision gearboxes, and (MK5) Hall effect homing on J1 to J3.
What changed from AR4-MK4 to MK5?
MK5 adds Hall effect homing sensors on J1 to J3, a new build manual and full DH kinematic sheets. MK3 and MK4 owners can add Hall effect homing with the $42.50 Hall Effect Sensor Upgrade and printed mounts from the MK4 to MK5 update manual.
Should I build an AR3 today?
The current design is the AR4-MK5, and it is the one the latest software, manual and kits support. Older revision downloads remain available for existing owners.
Are the AR3 and AR4 robots on AliExpress from Annin Robotics?
No. Those are counterfeits. They often cannot run the latest software and use open-loop encoders, weak drivers and gearboxes with backlash instead of the specified precision units.
Does the ROS 2 driver support MK5?
The ar4_ros_driver README lists ar_model options mk1 to mk4 (default mk4). Check the repository for current MK5 support before you start.