
Buyer's guide
Open Source Robot Arm
Six open source robot arms you can build, compared only on what each maker publishes.
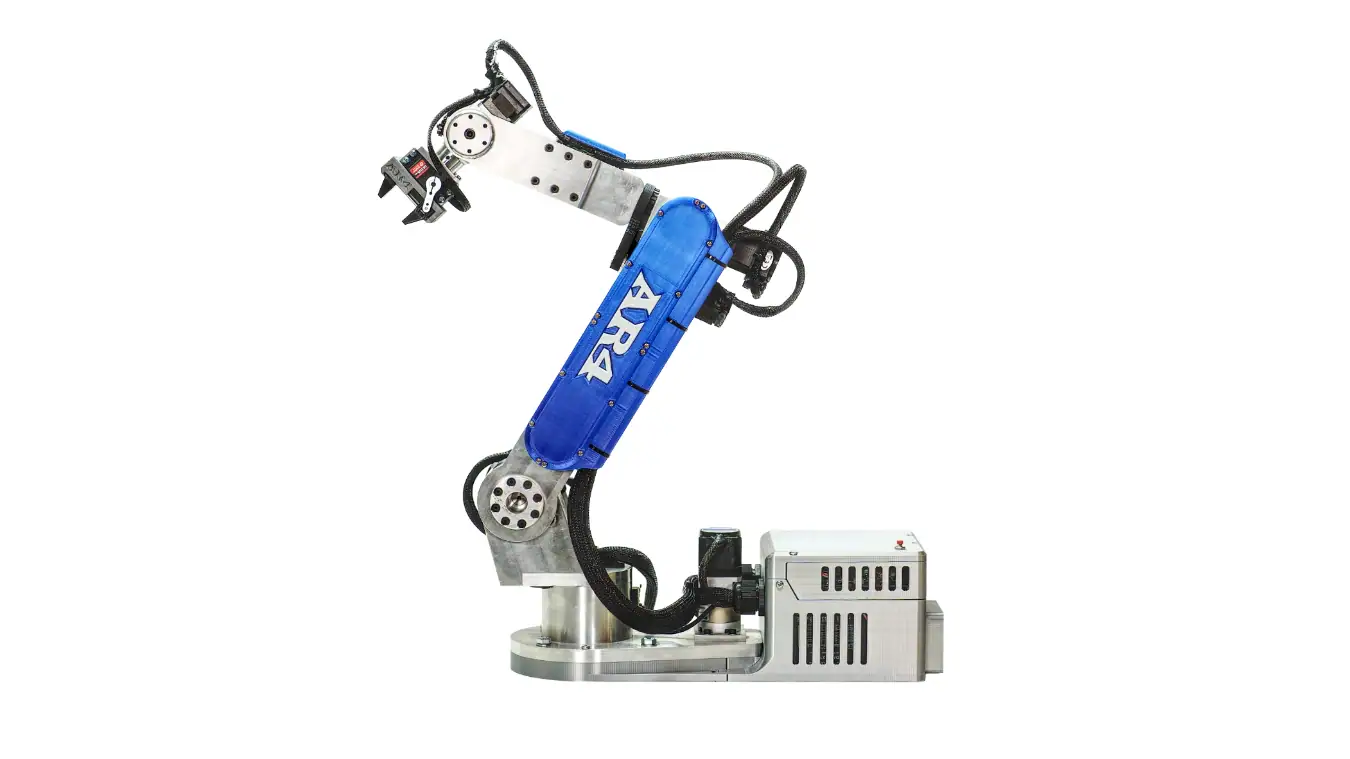
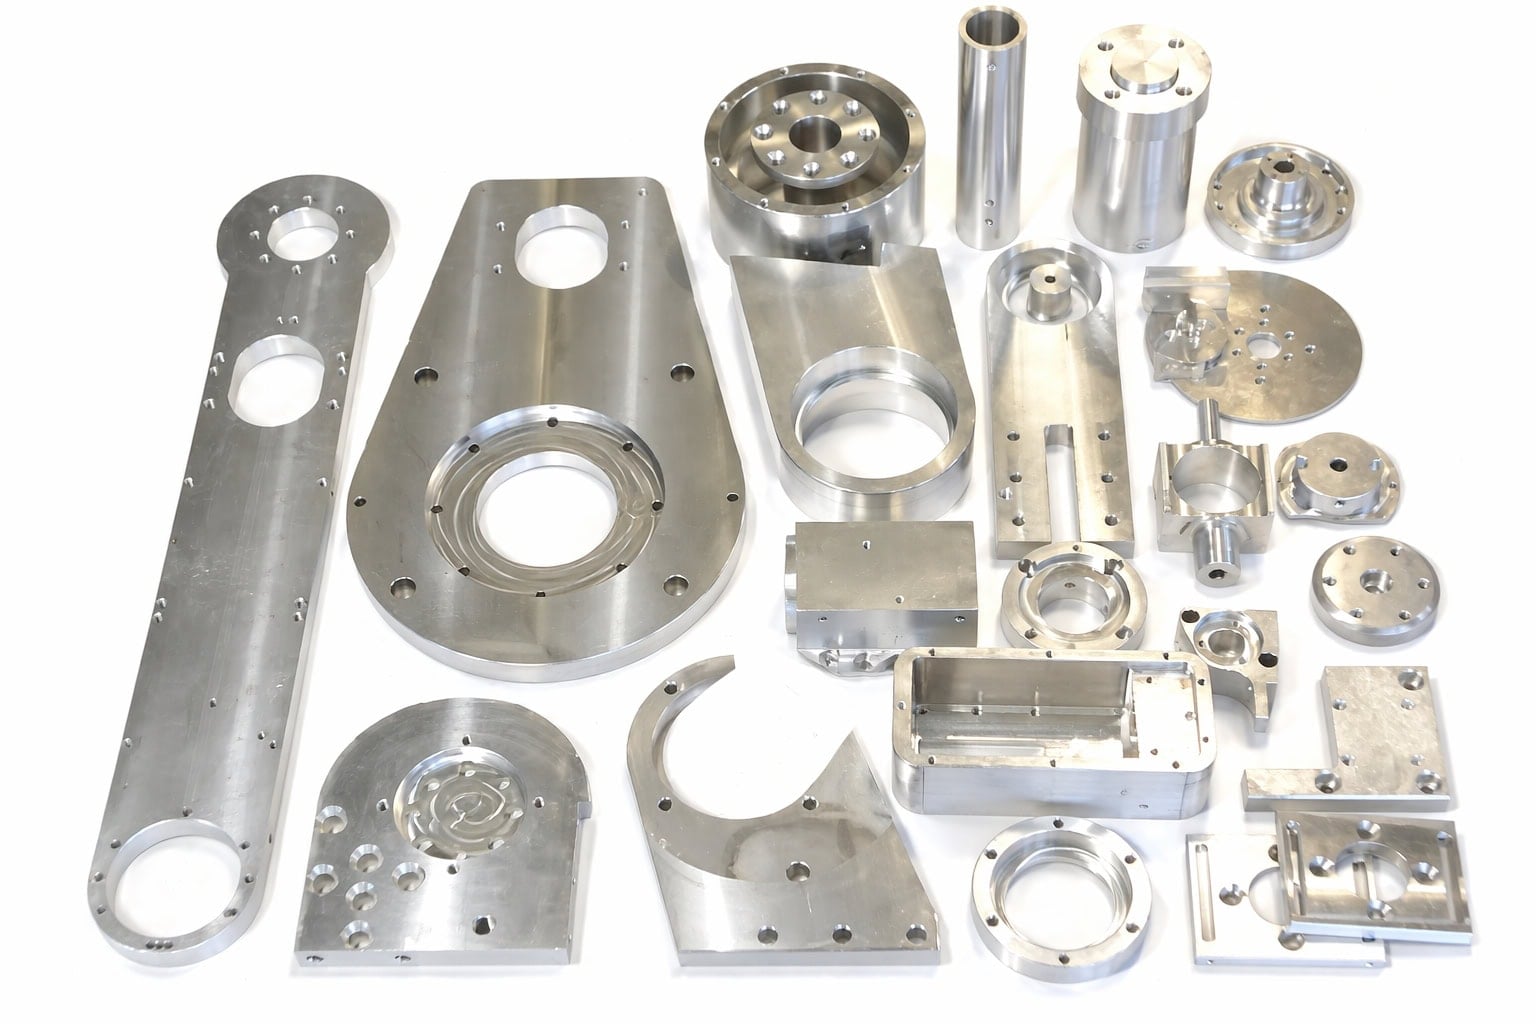
For the AR4's published files, license, and how to buy a kit or source parts yourself, see the open source robot arm kit guide.
How to choose
Payload and reach
Size the arm for the heaviest tool plus part, at the farthest point you need to reach.
Structure
Metal frames stay stiffer under load. Printed frames cost less and are easy to modify.
Software
Check for a ready HMI, ROS 2 support and simulation before you buy parts.
Feedback
Encoders or homing sensors let the arm recover position after a stall.
Total cost
Add motors, drivers, power, printed parts and a gripper, not just the frame.
Documentation
A full BOM, wiring and build guide save weeks.
Comparison table
"Not published" means the maker page we cite does not state it. Prices as listed by each maker in October 2026.
Annin Robotics
AR4 MK5
- Axes
- 6
- Reach
- 629 mm (24.75 in)
- Payload
- 1.9 kg (4.15 lb)
- Repeatability
- 0.25 mm
- Structure
- 26 machined aluminum structural parts, 3D printed PETG covers
- Software
- Python HMI with digital twin, ROS 2, Modbus, G-code
- Cost
- Combo kit $1,229 plus $699 motor package ($1,928 total)
Source Robotics
PAROL6
- Axes
- 6
- Reach
- 400 mm with standard gripper
- Payload
- 1 kg near the base, 0.5 kg across the workspace
- Repeatability
- 0.1 mm (docs), 0.2 mm (store page)
- Structure
- 3D printed PETG
- Software
- PAROL6 Commander (Python), open source GUI
- Cost
- Kit €2,378.81 without printed parts or power supply; assembled €3,570
AngelLM (Thor project)
Thor
- Axes
- 6
- Reach
- Not published (625 mm tall fully stretched)
- Payload
- 750 g max, including the tool
- Repeatability
- Not published
- Structure
- 3D printed (PLA or PETG), printed gears
- Software
- GRBL or RRF G-code; ROS 2 in Docker
- Cost
- Under €350 in hardware (per the project); you source parts
BCN3D Technologies
BCN3D Moveo
- Axes
- Not published
- Reach
- Not published
- Payload
- Not published
- Repeatability
- Not published
- Structure
- Fully 3D printed structure
- Software
- Arduino firmware
- Cost
- Not sold; open files and BOM on GitHub
Arctos Robotics
Arctos
- Axes
- 6
- Reach
- 600 mm
- Payload
- 2 kg
- Repeatability
- Not published
- Structure
- Mostly 3D printed
- Software
- Arctos Studio, ROS/ROS 2, GRBL, RoboDK, Isaac Sim, Matlab
- Cost
- Kits starting at $231
TheRobotStudio with Hugging Face
SO-101
- Axes
- 6 STS3215 servos per arm (joints and gripper)
- Reach
- Not published
- Payload
- Not published
- Repeatability
- Not published
- Structure
- 3D printed PLA+
- Software
- Hugging Face LeRobot
- Cost
- About $122 in parts for one follower arm (US list, printed parts extra)
Sources
FAQ
What is the best open source robot arm?
It depends on the job. For payload and a rigid metal structure, the AR4 has a machined aluminum frame and a 1.9 kg payload. For the lowest cost and AI teleoperation research, the SO-101 with LeRobot is popular. Printed arms like Thor and Moveo are cheap to source part by part.
Which open source robot arm has an aluminum structure?
Of the arms in this guide, the AR4 is the one built from machined aluminum structural parts. The others are mostly 3D printed.
Where do these numbers come from?
Only from each maker's own pages, linked in the sources list. When a maker does not publish a value we say so instead of guessing.
Can I use ROS 2 with these arms?
The AR4 has ROS 2 drivers with MoveIt and Gazebo. Thor and Arctos also list ROS 2 support on their pages.