
Kit guide
Open Source Robot Arm Kit: What You Get and How to Build
The AR4 open source robot arm kit publishes its build manual, print files, firmware, HMI source, kinematic sheets and a ROS 2 driver. You can buy the matched kits or source every part yourself from the bill of materials. Here is exactly what is published, what is sold, and what the license lets you do.
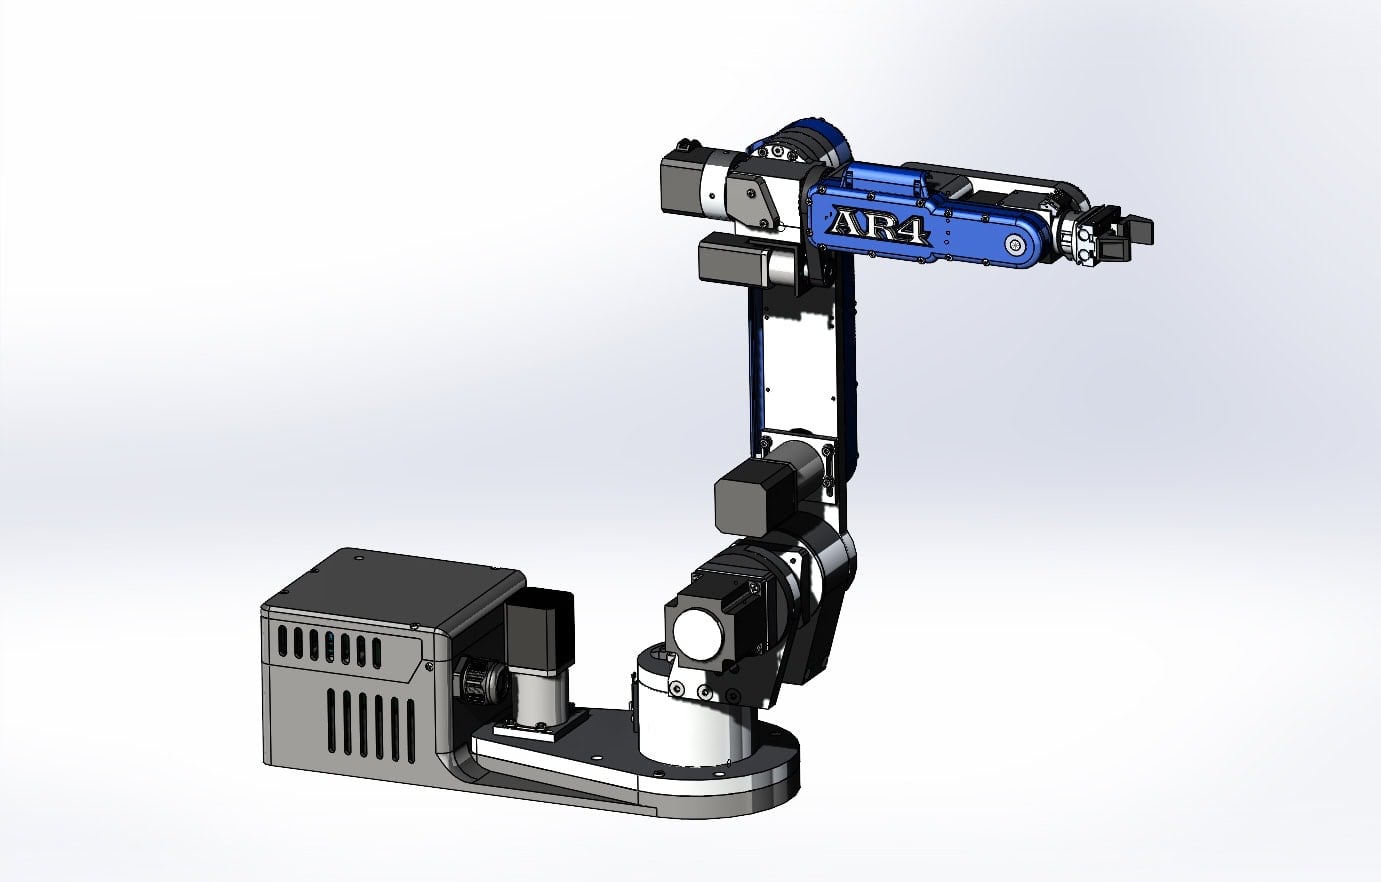
What the AR4 publishes
| Build manual | AR4-MK5 manual |
|---|---|
| Print files | STL files for printed covers and parts |
| Kinematics | Standard and modified DH parameter sheets |
| Motor setup | MK5 motor steps spreadsheet |
| Robot software | AR4 HMI (Python) source and Windows build |
| Firmware | Teensy 4.1 and Arduino Nano sketches |
| Python API | ARrobot.py library and user guide |
| ROS 2 | ar4_ros_driver: description, driver, firmware, MoveIt config and Gazebo |
| Native CAD | SOLIDWORKS and STEP: MK5 CAD package ($99) |
What the license allows
The AR4 is shared source with a non-commercial license, not a permissive license like MIT. In summary:
- You may share, copy and redistribute the software in any medium, with or without changes, free of charge to the recipient.
- Keep the copyright notice, give credit and say if you changed anything.
- Use it for education, hobby work and automating your own work.
- Selling robots, robot parts, or any versions of robots or software based on the work requires written permission.
This is a summary. The full license and terms of use ship with the software and on the product pages. If you plan a commercial product, ask first.
Why open matters on a robot arm
Repair
With the manual and every part sold separately, you can fix any joint yourself.
Learning
Students can read the kinematics, firmware and HMI they are running, not a black box.
Extending
Add axes, grippers, vision or a PLC link. The Python API and ROS 2 driver let you write your own control.
For a side by side look at other open arms (PAROL6, Thor, BCN3D Moveo, Arctos and SO-101), see the open source robot arm comparison.
Kit or self-source?
Sourcing every part yourself is allowed and documented. The kits exist so the machined aluminum, hardware and matched electronics arrive together and match the manual. You can also mix: buy the aluminum kit and source the rest.
Kit plus motors
$1,928
Combo kit $1,229 + StepperOnline motor package $699. Grippers and printed covers are extra.
Keep reading
FAQ
Is the AR4 open source?
The AR4 publishes its build manual, print files, software source, firmware and kinematic sheets, and the ROS 2 driver is on GitHub. The license is non-commercial: you may share and modify it free of charge with credit, but selling robots, parts or software based on it needs written permission.
Can I use the AR4 design in my school or lab?
Yes. The design is free for education, hobby and automating your own work. What the license does not allow is manufacturing the robot or its parts to resell.
Are the CAD files free?
The STL print files are free on the downloads page. The full native SOLIDWORKS assembly with STEP files is sold as the MK5 CAD package ($99).
Do I have to buy the kit to build an AR4?
No. You can source parts yourself from the manual's bill of materials. The kits exist so you get matched, machined parts in one order, and every part is also sold separately.
Where is the AR4 source code?
The HMI and Teensy sketch are on the downloads page and the Annin Robotics GitHub, along with the ar4_ros_driver for ROS 2. The Python API guide documents the ARrobot.py library.