
Research
A Robot Arm for AI Research
The AR4 is a 6 axis arm with open firmware, ROS 2 drivers and simulation, so your lab owns the whole stack from motor to model.
Why researchers pick the AR4
Payload
1.9 kg
Reach
629 mm
Repeat.
0.25 mm
- 1.9 kg payload, 629 mm reach and 0.25 mm repeatability.
- Encoder feedback on every joint.
- Open mechanical design, electronics, firmware and software.
- Python HMI, ROS 2, Modbus and G-code control.
- Every part sold separately, so a broken part is a quick fix.
Documented software and integrations
Each one is open source and linked to its repo. See ROS 2 for the AR4 and AR4 software for setup.
Open source
ROS 2 Jazzy driver
Annin Robotics driver for Ubuntu 24.04 with MoveIt motion planning and Gazebo simulation. Supports the servo gripper.
Open source
Ekumen ar4 packages
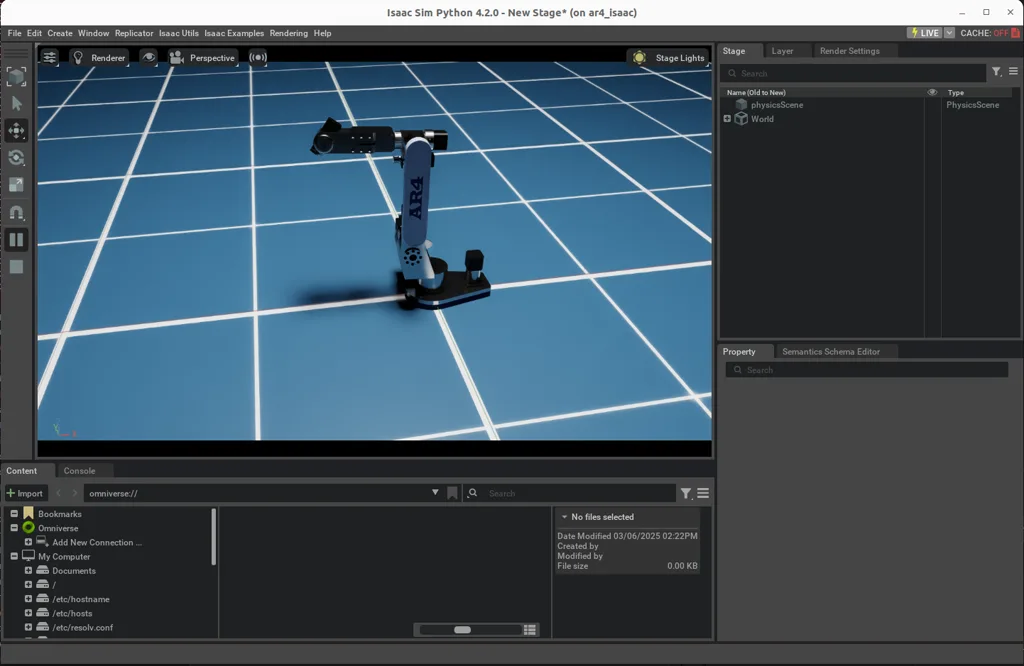
Community ROS 2 Humble and Iron packages with Gazebo, MuJoCo and Docker. Isaac Sim support is under development.
Open source
Hand eye calibration
Camera to arm calibration for vision based picking.
Open source
Driver examples
Xbox controller teleoperation and multi arm control.
Open source
Voice guided pick and place
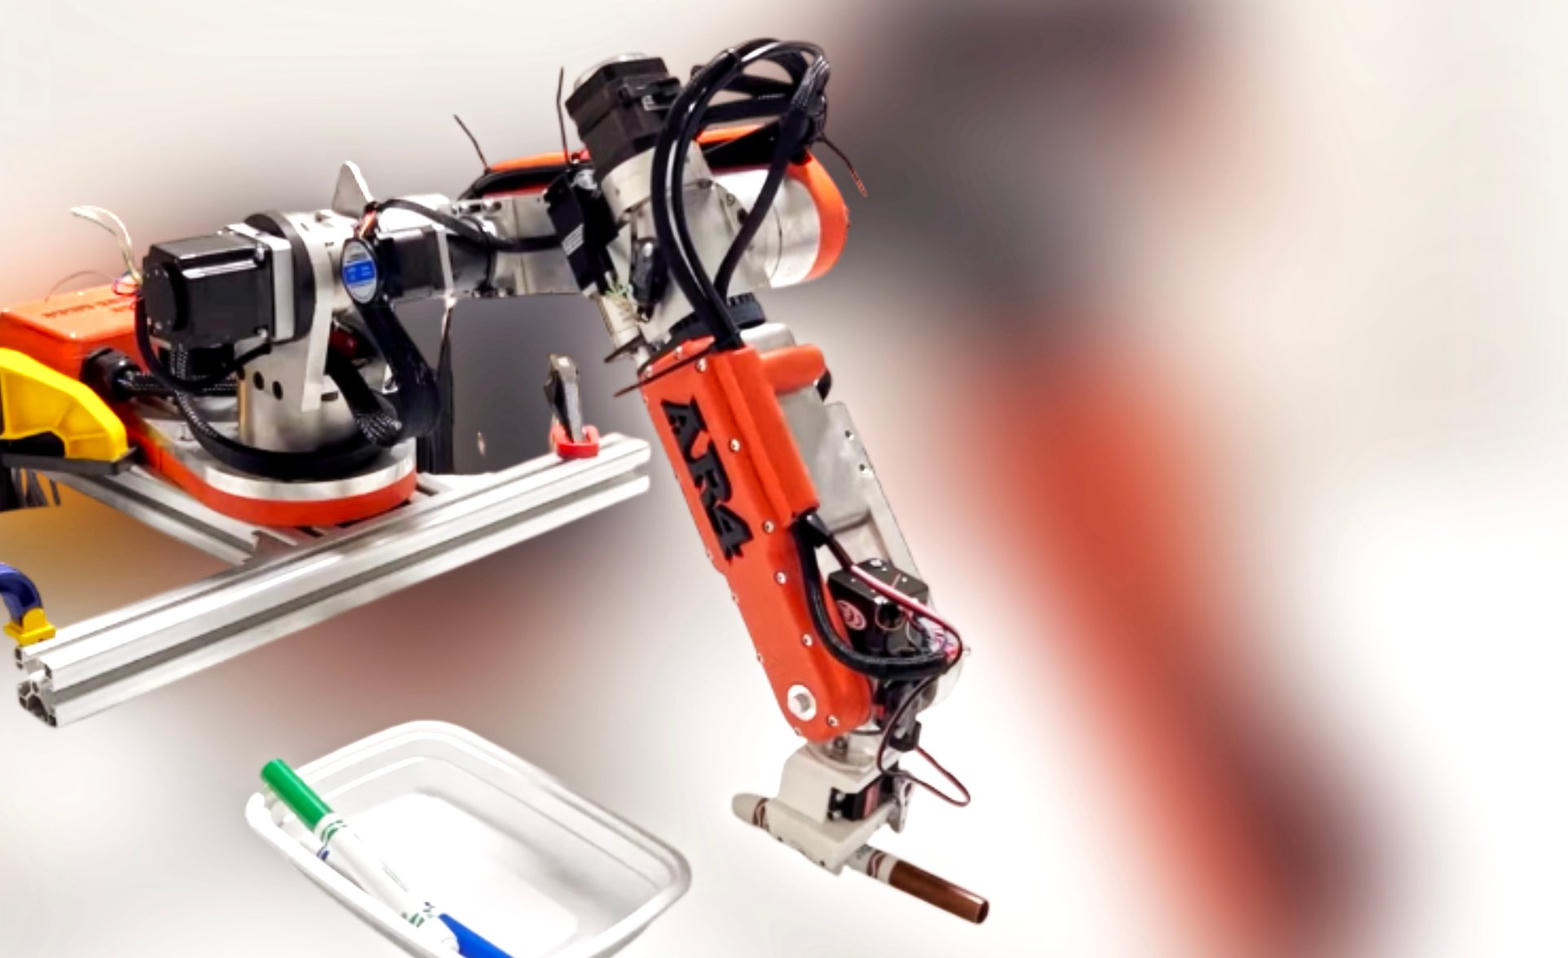
Grounding DINO, Segment Anything, Whisper and a RealSense D435 on a ROS 2 pipeline.
See it run
FAQ
Does the AR4 work with ROS 2?
Yes. The Annin Robotics ar4_ros_driver supports ROS 2 Jazzy on Ubuntu 24.04 with MoveIt and Gazebo. The community Ekumen ar4 packages support Humble and Iron with Gazebo, MuJoCo and Docker.
Can I simulate the AR4 before building it?
Yes. Gazebo and MuJoCo are supported through the ROS 2 packages, Isaac Sim support is under development in the Ekumen packages, and the Python HMI has a digital twin.
Has the AR4 been used with vision and language models?
Yes. The open source tabletop-handybot project runs voice guided pick and place on an AR4 with Grounding DINO, Segment Anything, Whisper and a RealSense D435.
Can I control it from my own code?
Yes. The firmware, Python HMI and ROS 2 drivers are open source, and the arm also speaks Modbus and G-code.